Starting viewport
Agility Robotics · biped
Cassie
Torso-less bipedal research robot spun out of Oregon State University and sold to research labs. Superseded by Digit, which reuses its leg design.
Frames · Cassie
8 items · credit and license on each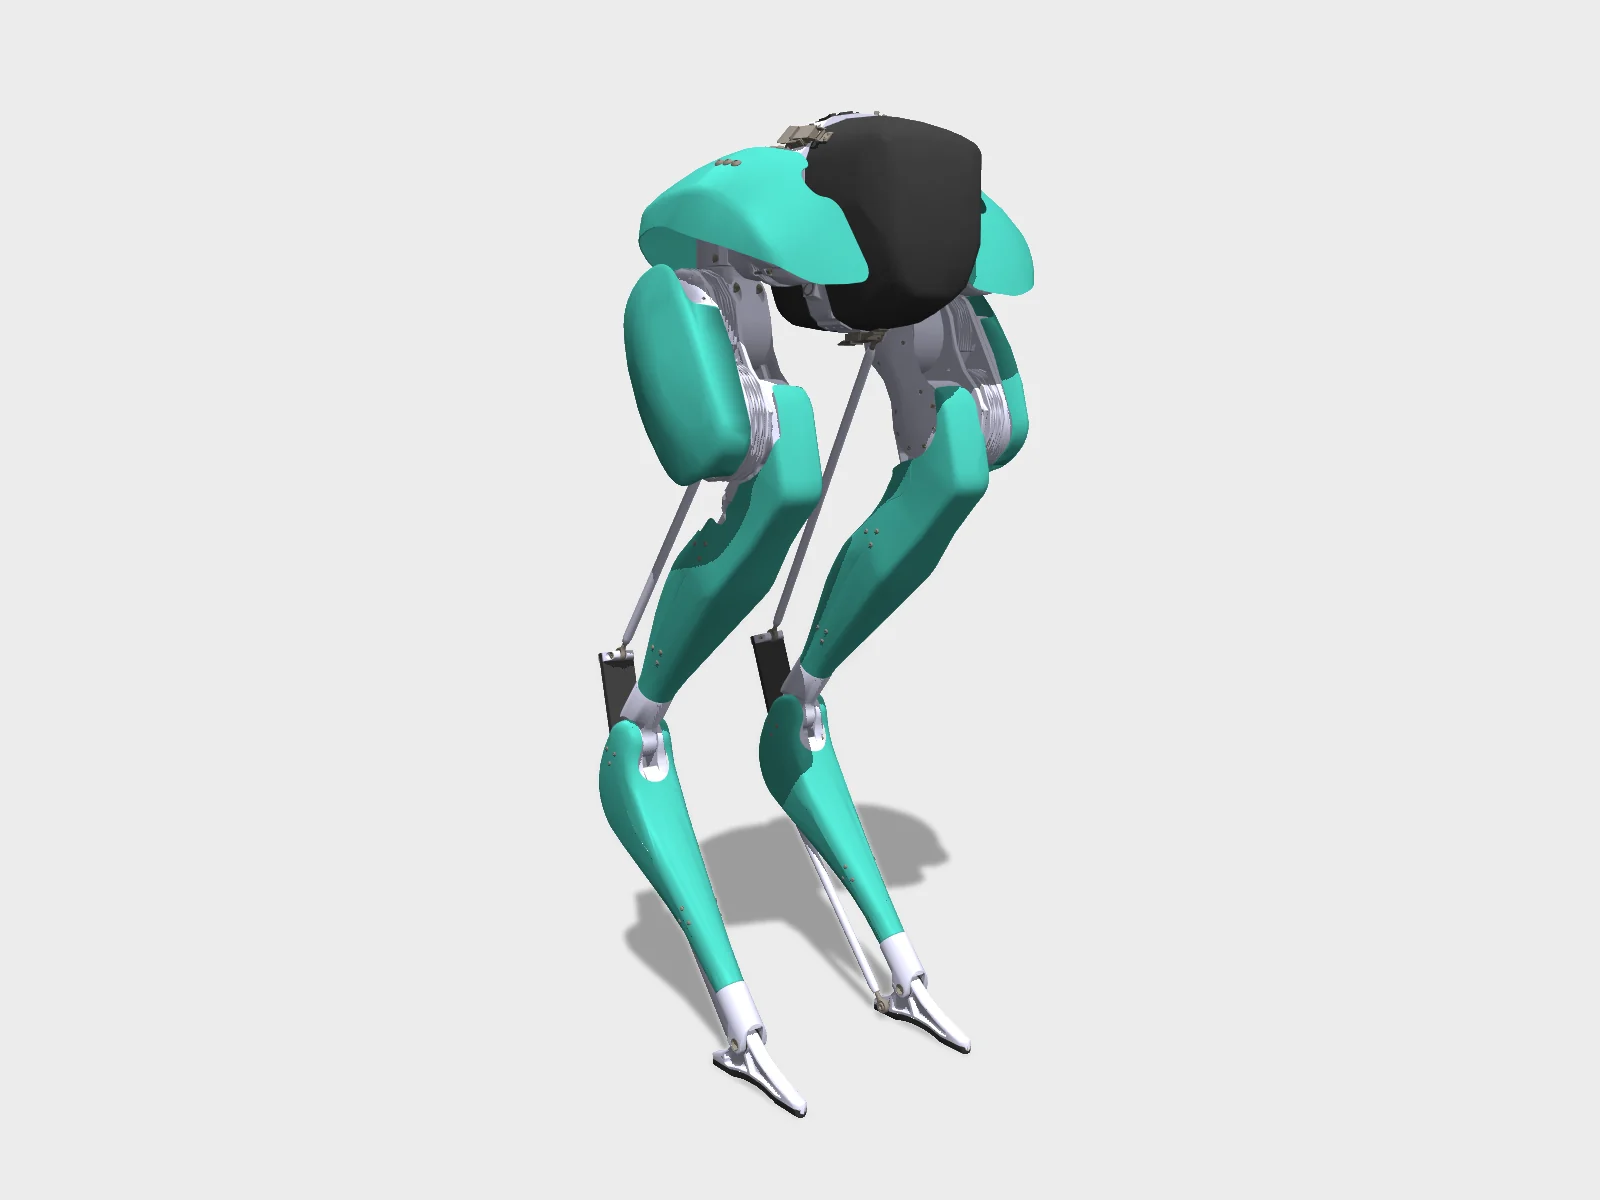
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 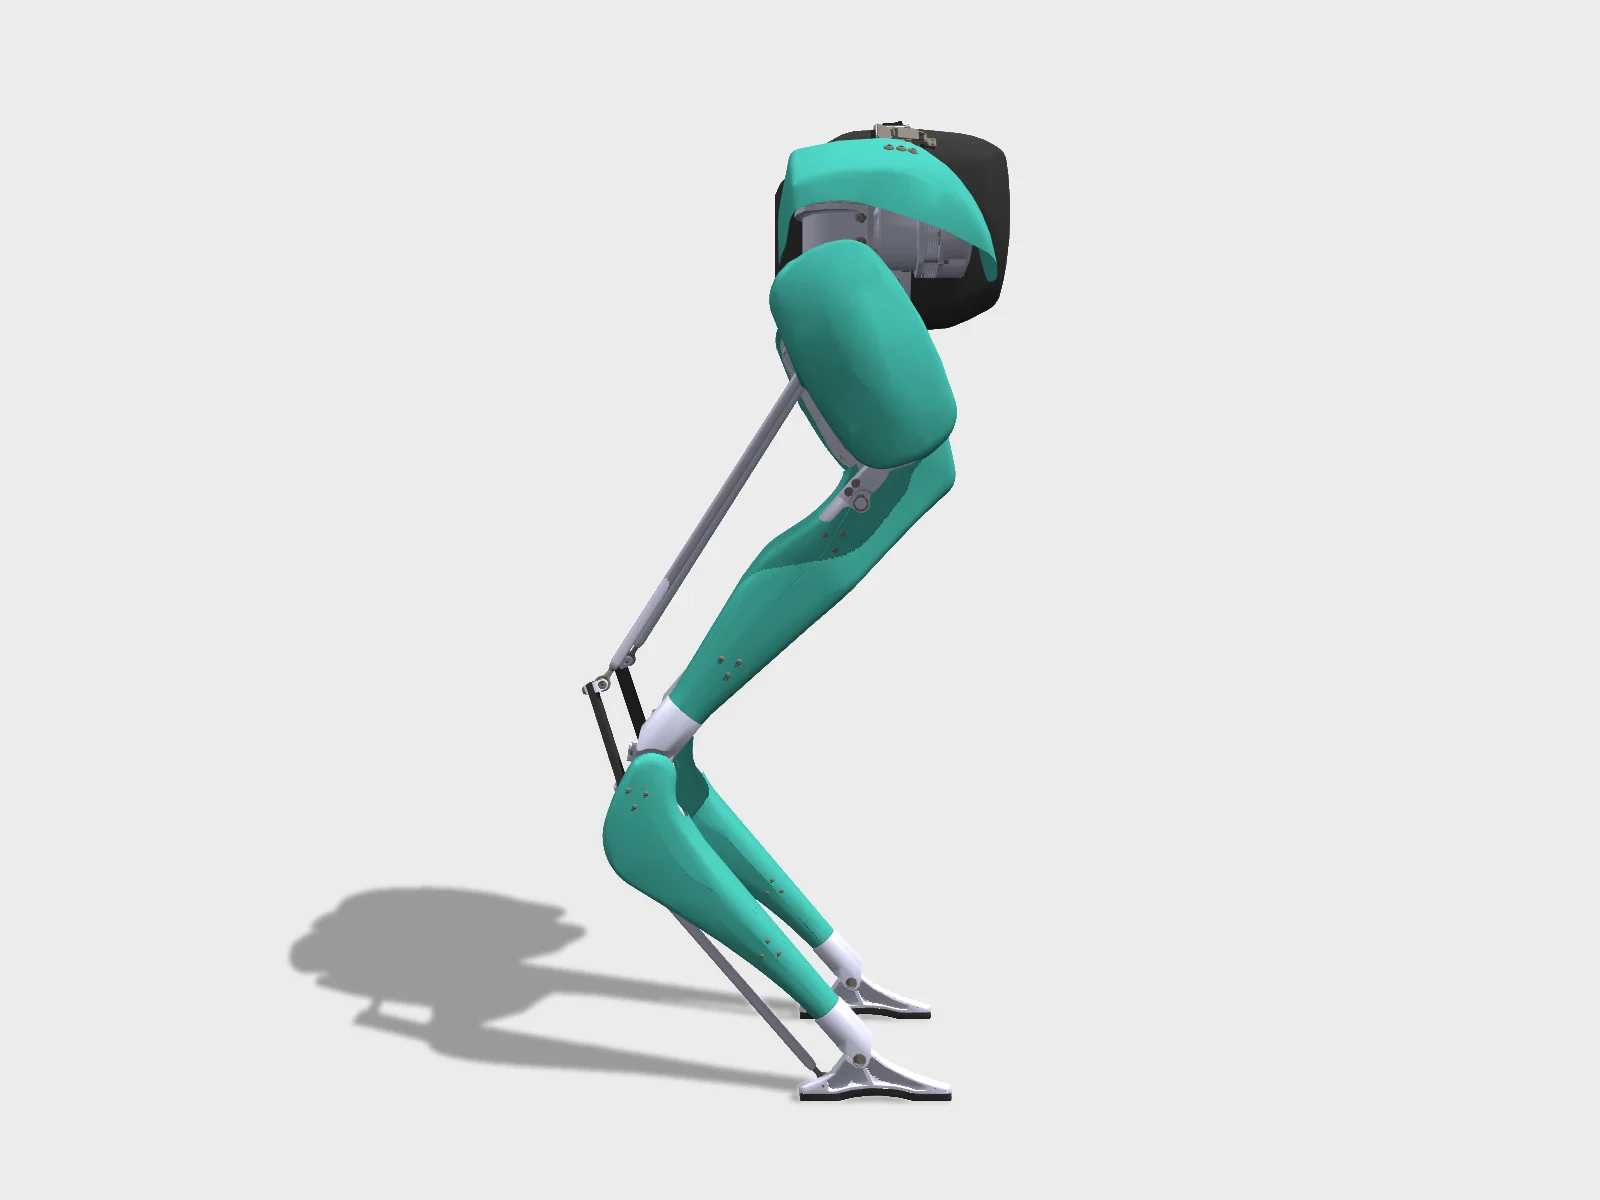
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 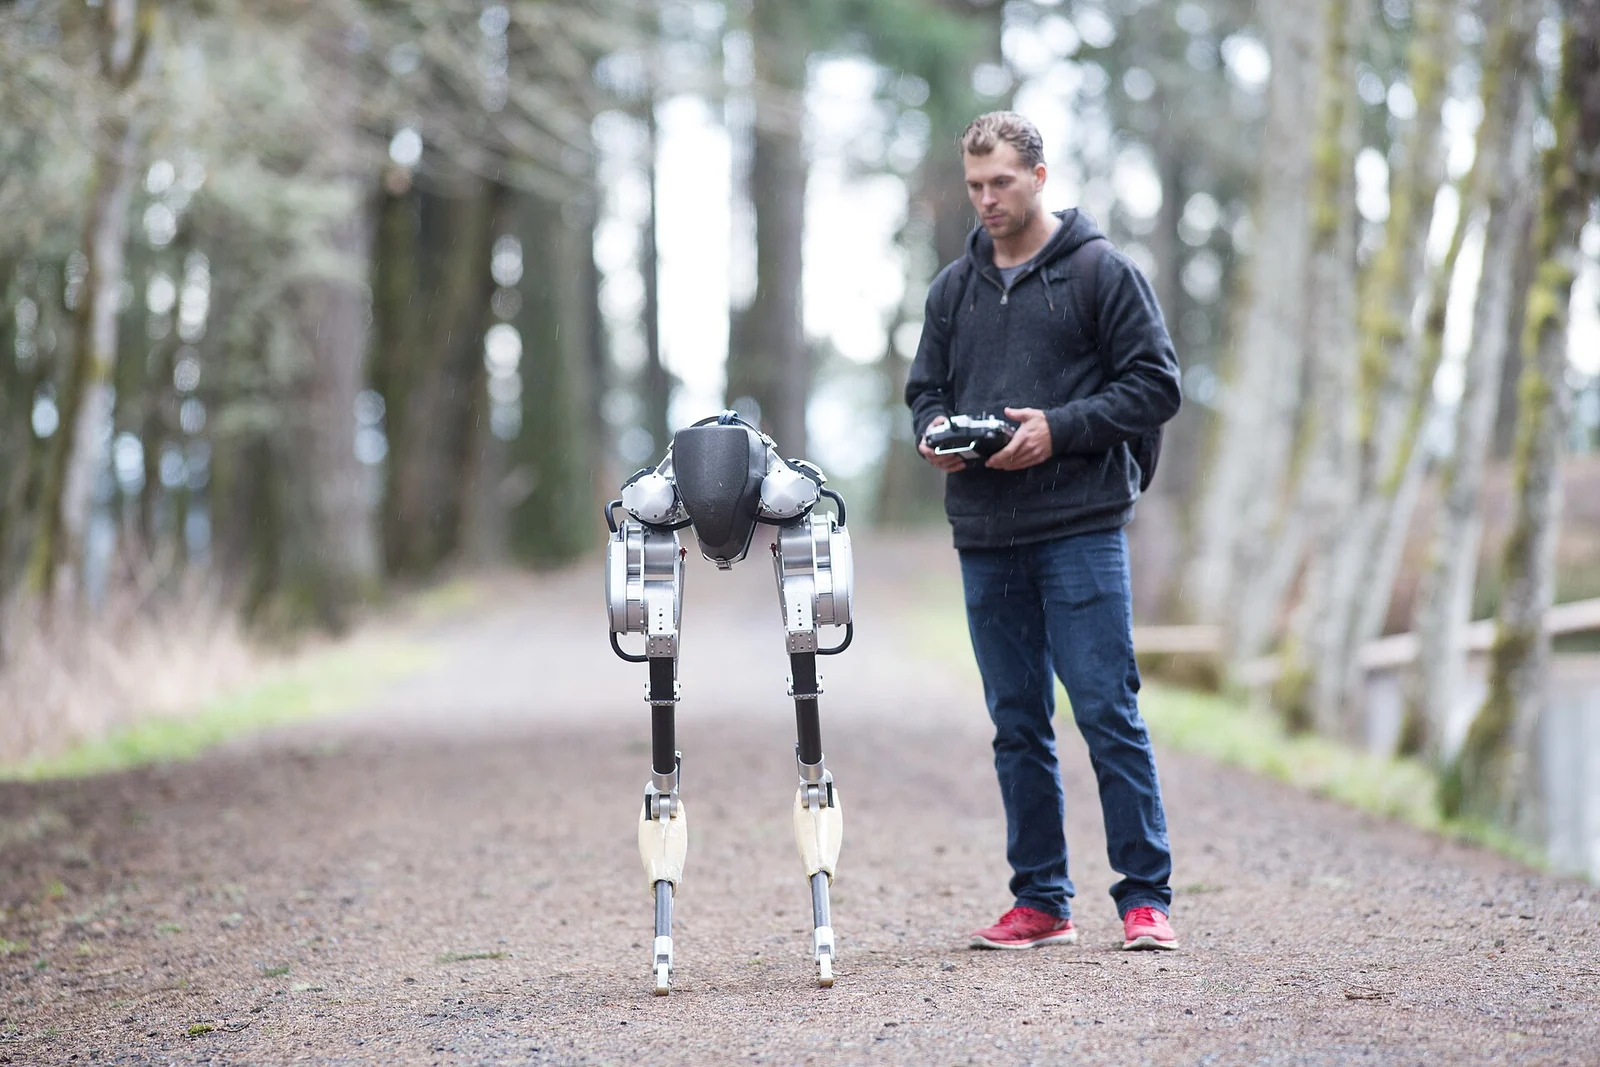
Via Wikimedia Commons (CC BY-SA 2.0).Oregon State University, via Wikimedia Commons · CC-BY-SA-2.0 · source 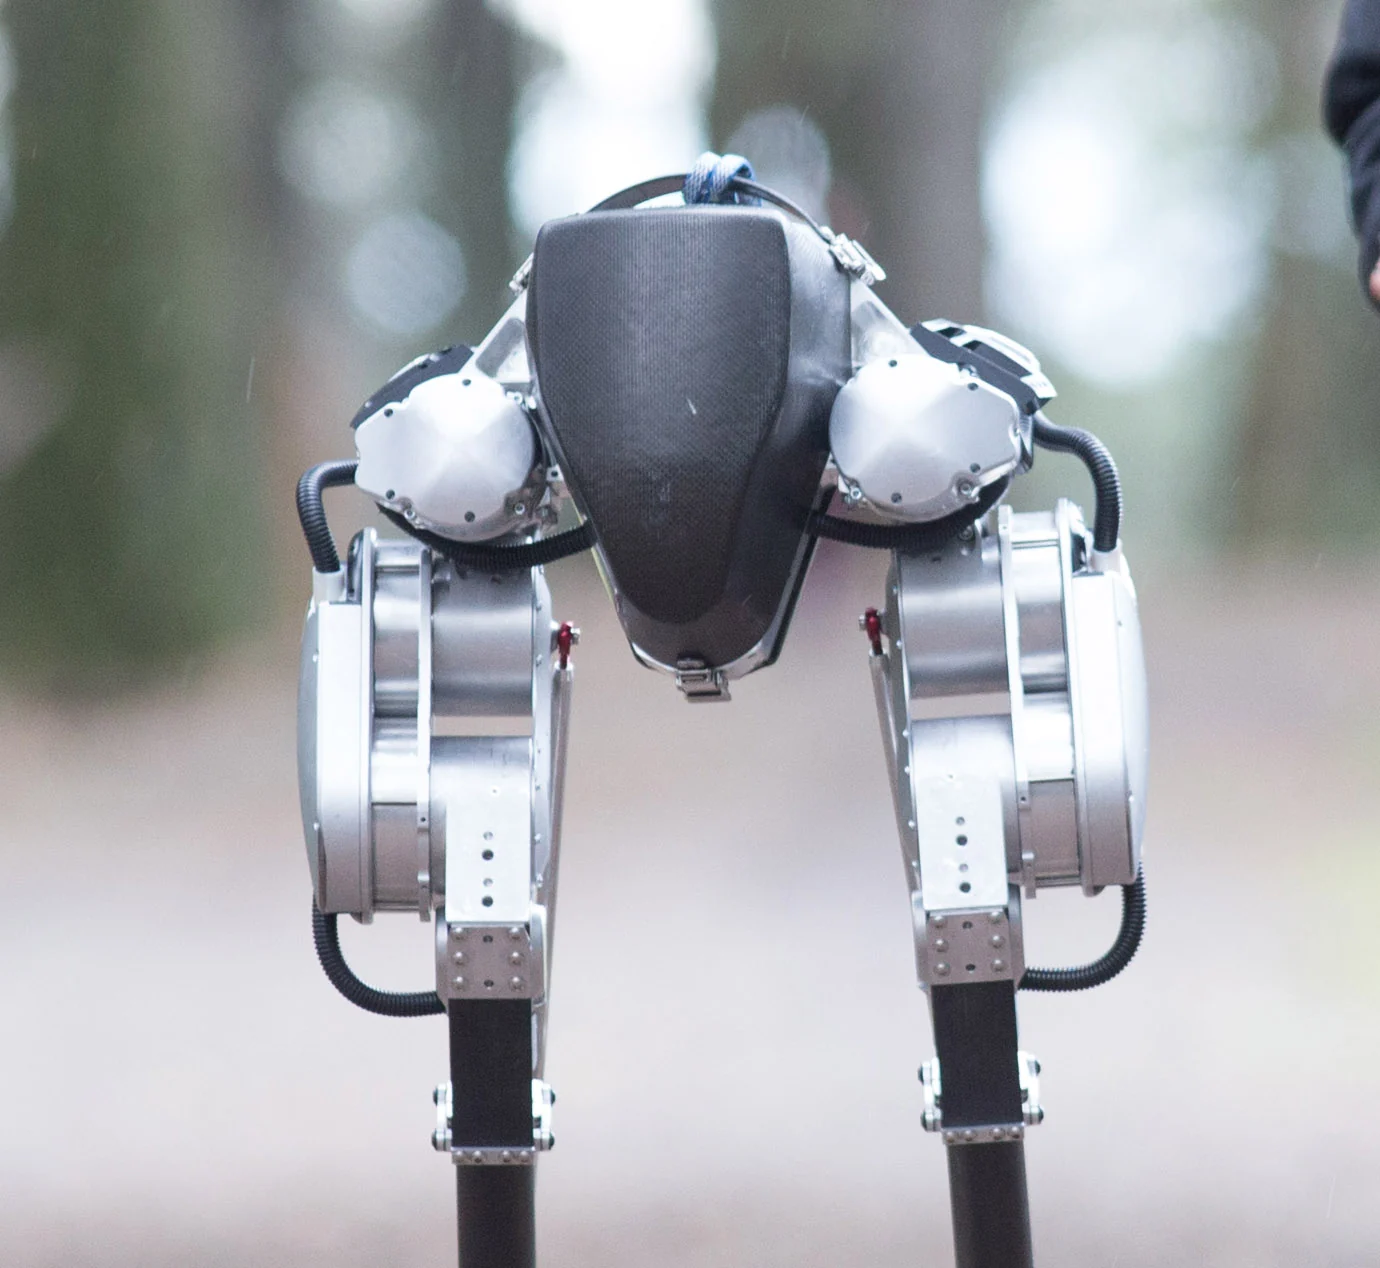
Via Wikimedia Commons (CC BY-SA 2.0).Oregon State University, via Wikimedia Commons · CC-BY-SA-2.0 · source Meet CassieAgility · official embed · source


+2 more on humanoidrobots.systems/agility/cassie
Provenance
- Model
- Agility Cassie
- Commit
- c96a32d28fb5
- Entry
- agility_cassie/scene.xml
- Files
- 16 · 4.9 MB, fetched from raw.githubusercontent.com, cached in your browser
- License
- MIT
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Caveat
- Loads and runs, but Cassie's compliant closed-chain legs need a dedicated controller; our generic PD stand hold lets it fold.
Policies listed for Cassie
No published policy we can replay yet.
Nothing is playing a trained controller in the viewport above. What you see is a PD hold on the stand pose, computed in your tab. A policy plays here when a checkpoint is published with an obs/action contract we can reproduce exactly in MuJoCo, and it passes a 30 s walk test in the tab.
Set up a training runTrain on GPUs
mjlab ships no stock task for Cassie. The training page gives you the pinned model and the steps to write a robot config.