Starting viewport
Unitree H1 walking in your tab on its maker's published policy. MuJoCo physics, ONNX inference, no install.
WASD or drag the pad to steer · Q E turn · P push · Drag to orbit · drop a URDF or MJCF on the viewport
Two tiers, one model file
01 The tab
Free, instant
- Physics
- MuJoCo 3.14, official WebAssembly build
- Render
- three.js, geoms read from the compiled model
- Input
- MJCF from the model's repo, or your own URDF/MJCF
- Policies
- 3 published walking policies replayed with onnxruntime-web, contract copied from each maker's sim2sim script
- You can
- steer a walking policy, pose joints, push, go limp, record WebM
- Limits
- one robot, CPU, single thread; inference only, no learning
02 Cloud GPUs
Queued on request
- Physics
- MuJoCo Warp on NVIDIA GPUs
- Training
- mjlab (Isaac Lab API) for locomotion and tracking; Newton for contact-rich work
- Scale
- thousands of parallel environments
- Output
- policy checkpoint, obs/action contract, eval video
- Limits
- does not run in a browser; needs CUDA via Warp
mjlab and Newton are GPU frameworks built on NVIDIA Warp. They do not run in a tab and this site does not pretend they do. What connects the tiers is the file: both load the same MJCF, so a policy trained on GPUs replays against the same model you poke here. Build a training job.
Instruments
Flagship open platform · Hyperspawn's own robot · featured, not ranked
Hyperspawn render
● hyperspawn/dropbearHyperspawn Robotics
Train Dropbear.
Full-size open-source humanoid from Hyperspawn and Pointblank: FDM-printed structure on 20x20 aluminium extrusion, MyActuator CAN actuators, an ESP32 node per limb and a Jetson Orin brain. CAD, BOM, printables, firmware, URDF/MJCF/USD and simulation walking policies are public; a pre-assembled kit is on preorder.
- In the tab
- deployable walk, recorded in Isaac Lab and replayed · 1.5 MB
- Sim model
- Hyperspawn/dropbear-wbc · 23 KB · live physics, PD stand
- Published policies
- 2 in the zoo
- Stand-hold bench
- pass · 2026-10-11
- DOF
- 32
Humanoids with an open train verb · 28
Bring your own →| Robot | Maker | Browser model | In the tab | Download | Train verb |
|---|---|---|---|---|---|
 Adam Litepndbotics/adam-lite | PNDbotics | google-deepmind/mujoco_menagerie | PD hold | 395 KB | live |
| AgiBot Lingxi X1agibot/x1 | AgiBot (Zhiyuan Robotics) | AgibotTech/agibot_x1_train | PD hold | 36 MB | live |
 Apolloapptronik/apollo | Apptronik | google-deepmind/mujoco_menagerie | PD hold | 68 MB | live |
 Asimov 1menlo/asimov | Menlo Research (Asimov) | menloresearch/asimov-1 | PD hold | 41 MB | live |
 Berkeley Humanoid Liteberkeley/humanoid-lite | UC Berkeley Hybrid Robotics Lab | HybridRobotics/berkeley-humanoid-lite-assets | PD hold | 41 MB | live |
 Booster K1booster/k1 | Booster Robotics | BoosterRobotics/booster_assets | PD hold | 11 MB | live |
 Booster T1booster/t1 | Booster Robotics | google-deepmind/mujoco_menagerie | walks · policy | 8.1 MB | live |
 Dropbearhyperspawn/dropbear | Hyperspawn Robotics | Hyperspawn/dropbear-wbc | PD hold | 23 KB | live |
| EngineAI PM01engineai/pm01 | EngineAI (Zhongqing Robotics) | engineai-robotics/engineai_ros2_workspace | PD hold | 64 MB | live |
 Fourier GR-1fourier/gr1 | Fourier (Fourier Intelligence) | FFTAI/Wiki-GRx-MJCF | PD hold | 16 MB | live |
 Fourier GR-2fourier/gr2 | Fourier (Fourier Intelligence) | FFTAI/Wiki-GRx-MJCF | PD hold | 9.4 MB | live |
 Fourier N1fourier/n1 | Fourier (Fourier Intelligence) | google-deepmind/mujoco_menagerie | PD hold | 61 MB | live |
 HopeJRhuggingface/hopejr | The Robot Studio & Hugging Face | not packaged yet | - | - | live |
 K-Botkscale/kbot | K-Scale Labs | kscalelabs/kbot-models | PD hold | 15 MB | live |
| Kangaroopal/kangaroo | PAL Robotics | pal-robotics/kangaroo_simulation | PD hold | 28 MB | live |
| Leju Kuavoleju/kuavo | Leju Robotics | LejuRobotics/Leju-GMR | PD hold | 23 MB | live |
 Poppy Humanoidpoppy/poppy-humanoid | Poppy Project (Inria Flowers) | poppy-project/poppy-humanoid | PD hold | 224 KB | live |
 Rainbow Robotics RB-Y1rainbow/rby1 | Rainbow Robotics | google-deepmind/mujoco_menagerie | PD hold | 16 MB | live |
 Reachy 2pollen/reachy2 | Pollen Robotics (Hugging Face) | pollen-robotics/reachy2_mujoco | PD hold | 18 MB | live |
 ROBOTIS OP3robotis/op3 | ROBOTIS | google-deepmind/mujoco_menagerie | PD hold | 45 MB | live |
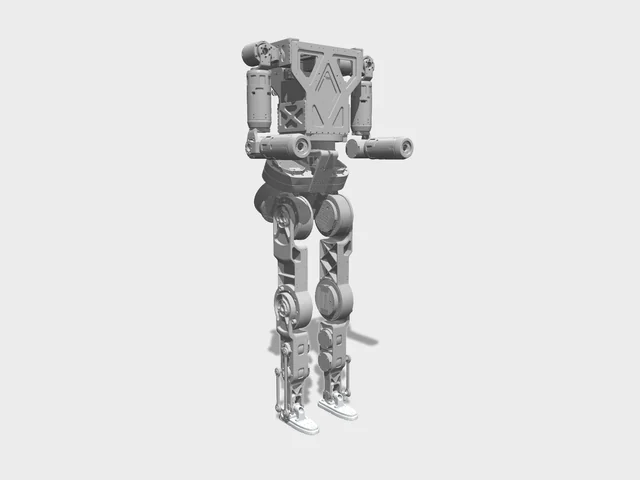 ROBOTO_ORIGINroboparty/roboto-origin | RoboParty (Shanghai RoboParty Technology) | Roboparty/roboto_origin | PD hold | 30 MB | live |
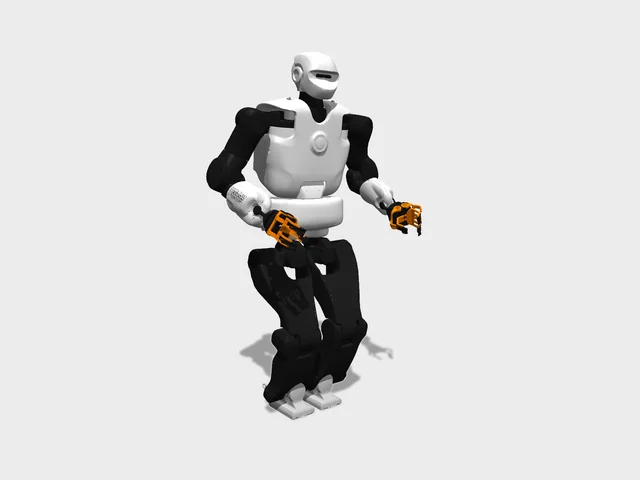 TALOSpal/talos | PAL Robotics | google-deepmind/mujoco_menagerie | PD hold | 7.6 MB | live |
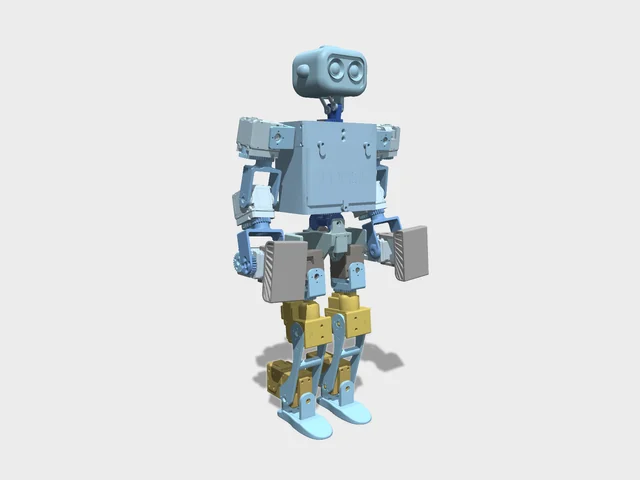 ToddlerBotstanford/toddlerbot | Stanford University | google-deepmind/mujoco_menagerie | PD hold | 65 MB | live |
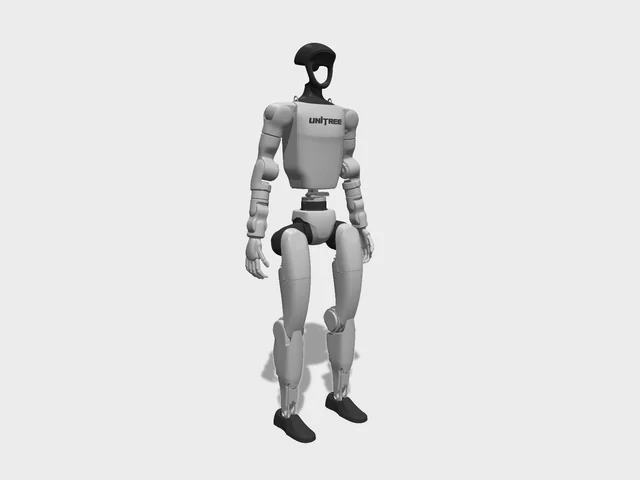 Unitree G1unitree/g1 | Unitree Robotics | google-deepmind/mujoco_menagerie | walks · policy | 19 MB | live |
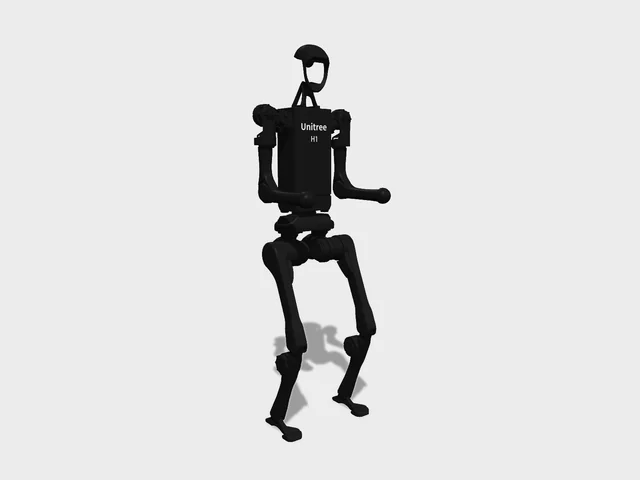 Unitree H1unitree/h1 | Unitree Robotics | google-deepmind/mujoco_menagerie | walks · policy | 14 MB | live |
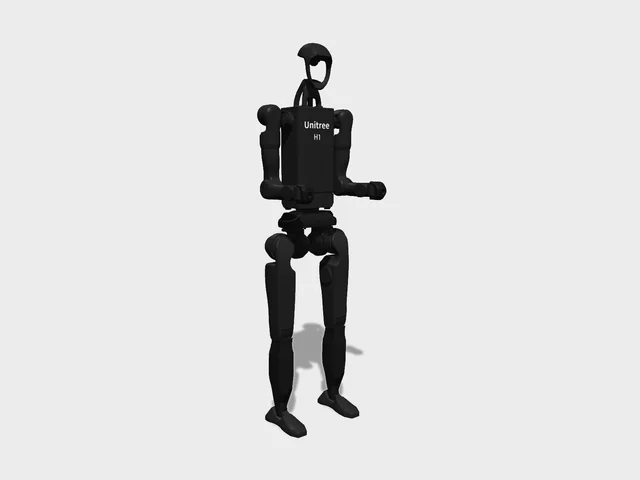 Unitree H1-2unitree/h1-2 | Unitree Robotics | unitreerobotics/unitree_mujoco | PD hold | 26 MB | live |
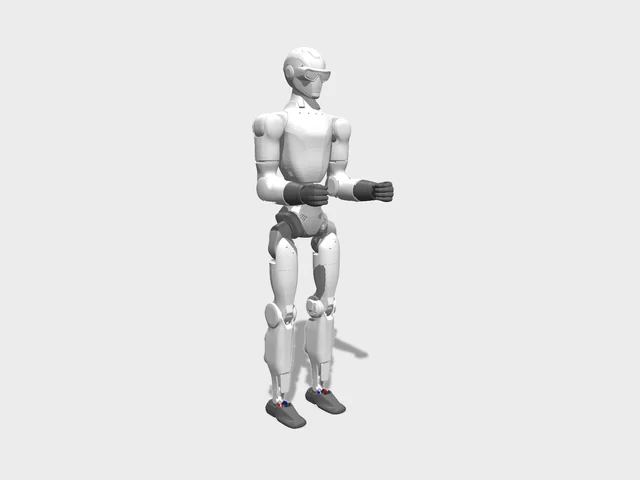 Unitree R1unitree/r1 | Unitree Robotics | unitreerobotics/unitree_mujoco | PD hold | 21 MB | live |
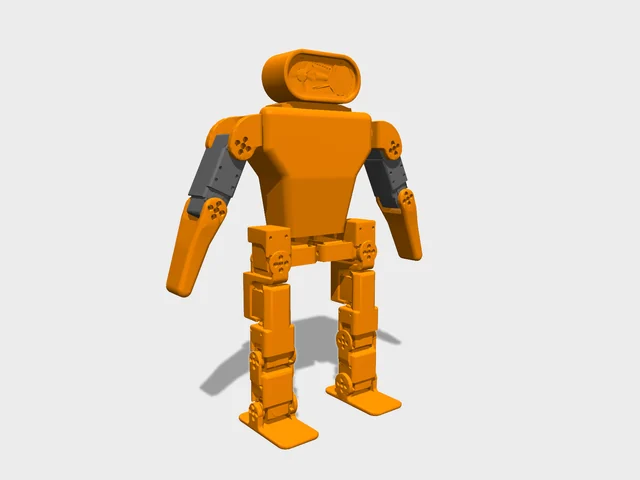 Z-Bot (Zeroth Bot)kscale/zbot | K-Scale Labs | kscalelabs/kscale-assets | PD hold | 6.4 MB | live |
Humanoids only. Arms, hands, quadrupeds, rovers and legs-only bipeds are on buildrobots.io.