Starting viewport
Menlo Research (Asimov) · humanoid
Asimov 1
1.2 m, 35 kg open-source biped with 25 actuated DOF, sold as an unassembled DIY kit or self-sourced from the published BOM and CAD.
Frames · Asimov 1
5 items · credit and license on each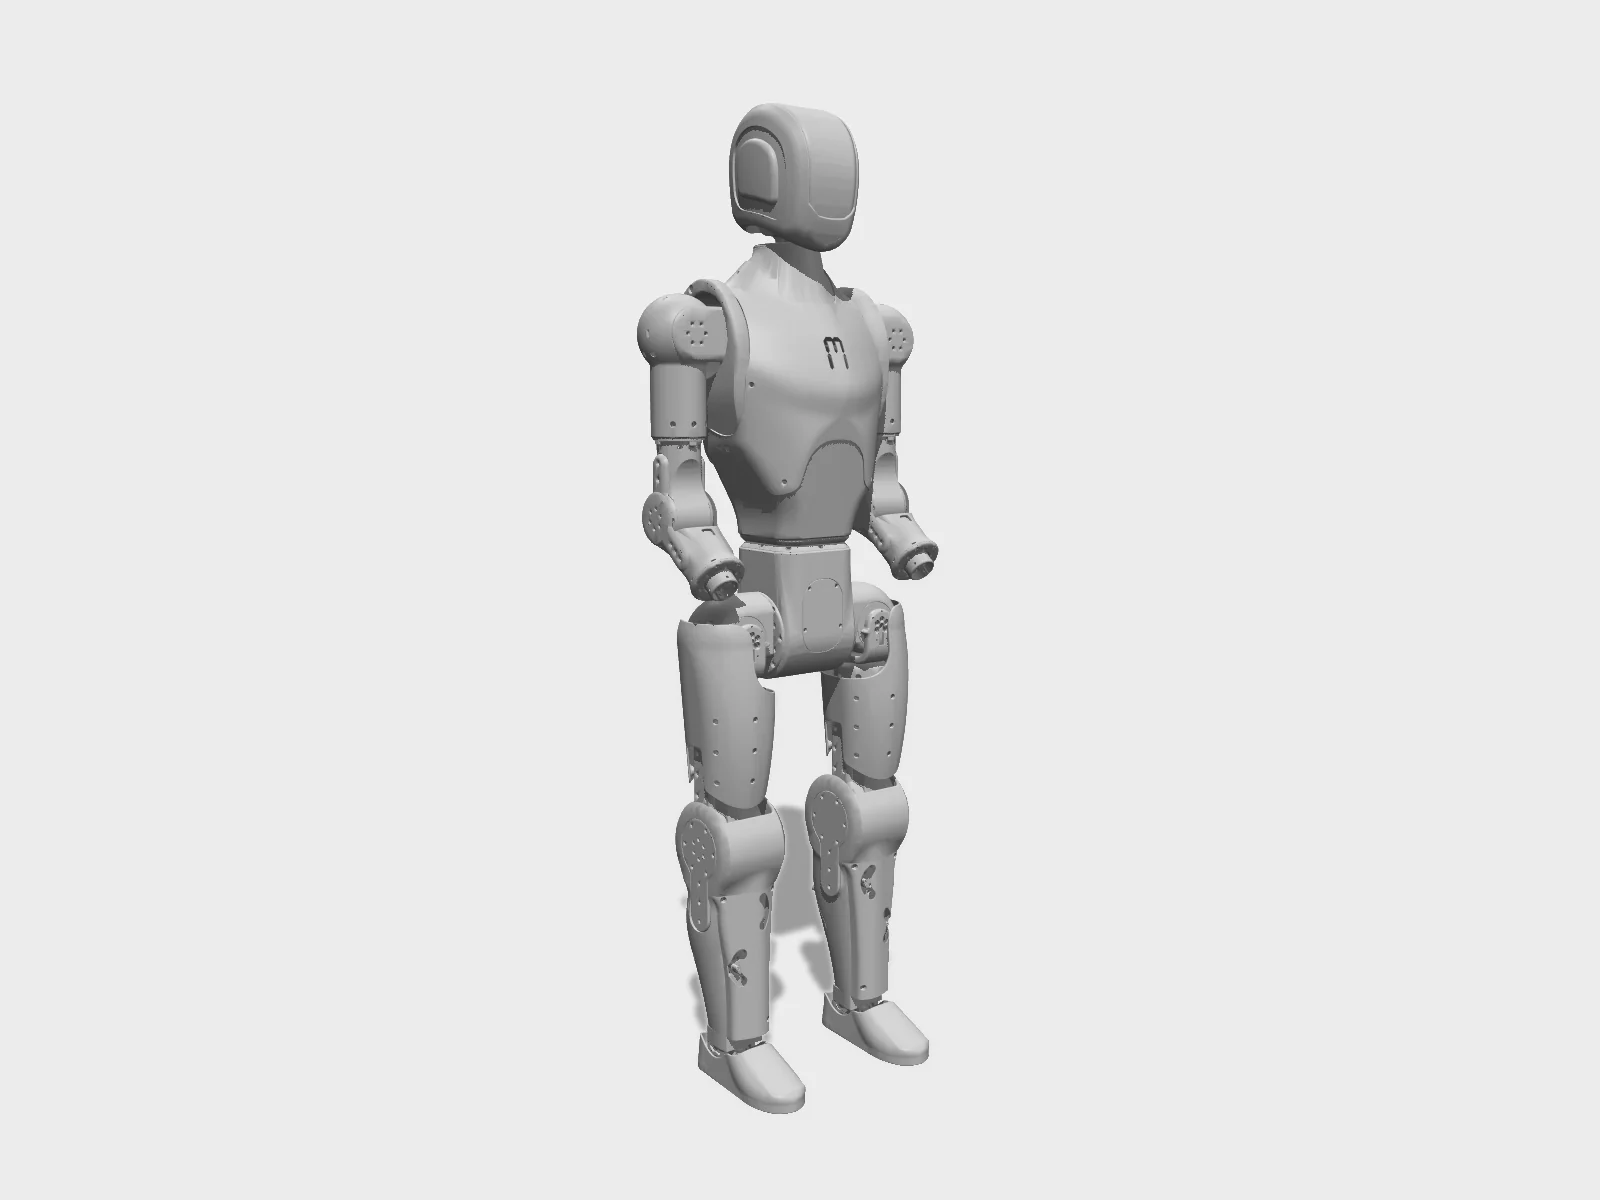
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from menloresearch/asimov-1 (CERN-OHL-S-2.0) · Hyperspawn render · source 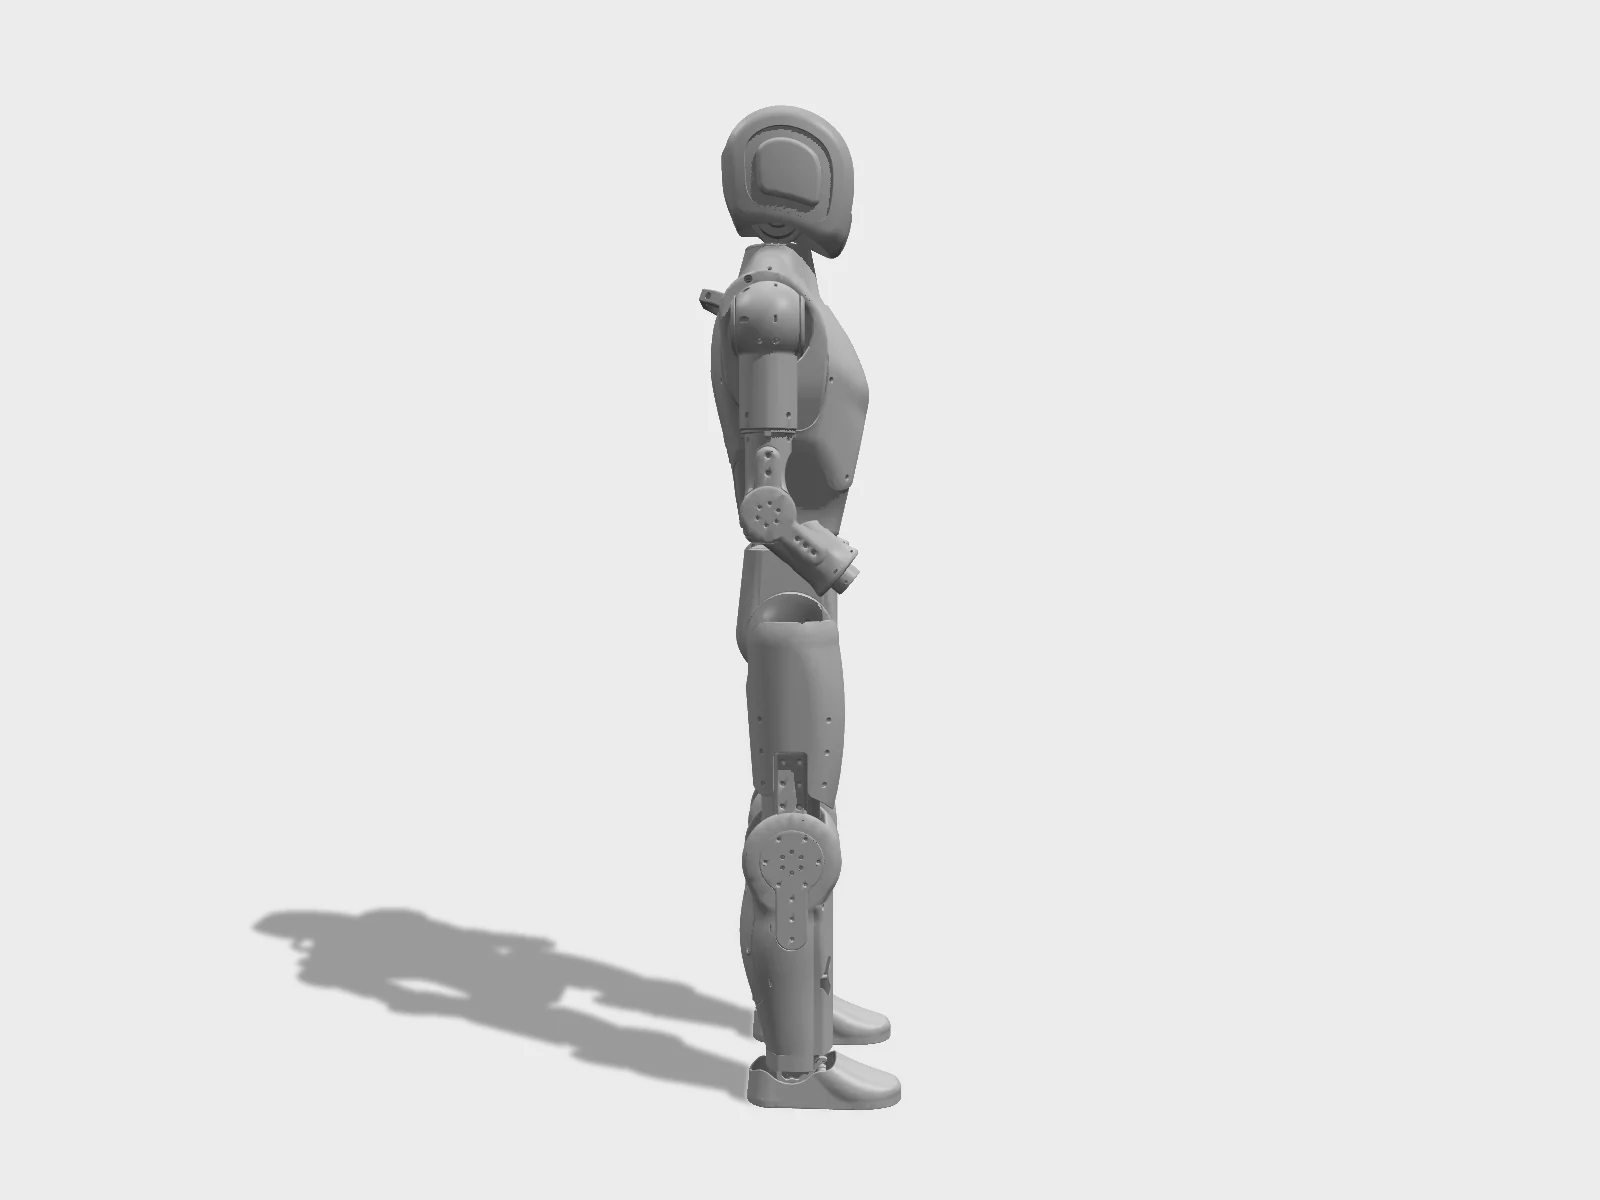
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from menloresearch/asimov-1 (CERN-OHL-S-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from menloresearch/asimov-1 (CERN-OHL-S-2.0) · Hyperspawn render · source 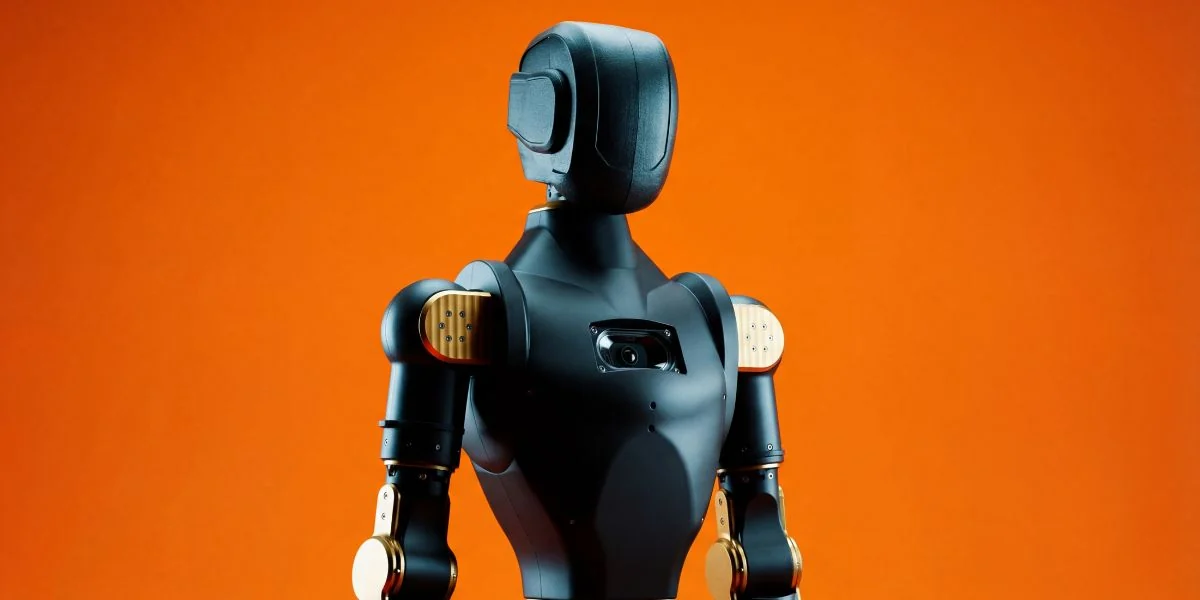
From the asimov-1 README.Menlo Research (asimov-1) · CERN-OHL-S-2.0 · source We're open-sourcing Asimov v1, a humanoid robotAsimov · official embed · source

Provenance
- Model
- Menlo Asimov
- Commit
- f71f3fe87ddf
- Entry
- sim-model/xmls/asimov_1.xml
- Files
- 26 · 41 MB, fetched from raw.githubusercontent.com, cached in your browser
- License
- CERN-OHL-S-2.0
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Note
- Published without actuators; the tab adds a position servo per joint from its range and effort limit.
Policies listed for Asimov 1
- source
Full-body velocity locomotion (23-DOF, neck locked)
Isaac Lab or MJLab templates (per docs); MuJoCo/URDF models in repo · not replayed in the tab
- source
Sim model for training
MuJoCo 3.x · not replayed in the tab
- source
Asimov v0 12-DOF biped velocity tracking (legs-only predecessor)
mjlab (MuJoCo Warp) RL · not replayed in the tab
Train on GPUs
mjlab ships no stock task for Asimov 1. The training page gives you the pinned model and the steps to write a robot config.