Starting viewport
Hyperspawn Robotics · humanoid
Dropbear
Full-size open-source humanoid from Hyperspawn and Pointblank: FDM-printed structure on 20x20 aluminium extrusion, MyActuator CAN actuators, an ESP32 node per limb and a Jetson Orin brain. CAD, BOM, printables, firmware, URDF/MJCF/USD and simulation walking policies are public; a pre-assembled kit is on preorder.
Frames · Dropbear
17 items · credit and license on eachTurntable render of the current Dropbear build. Looping, muted, 5.3 s.Hyperspawn · Hyperspawn · source 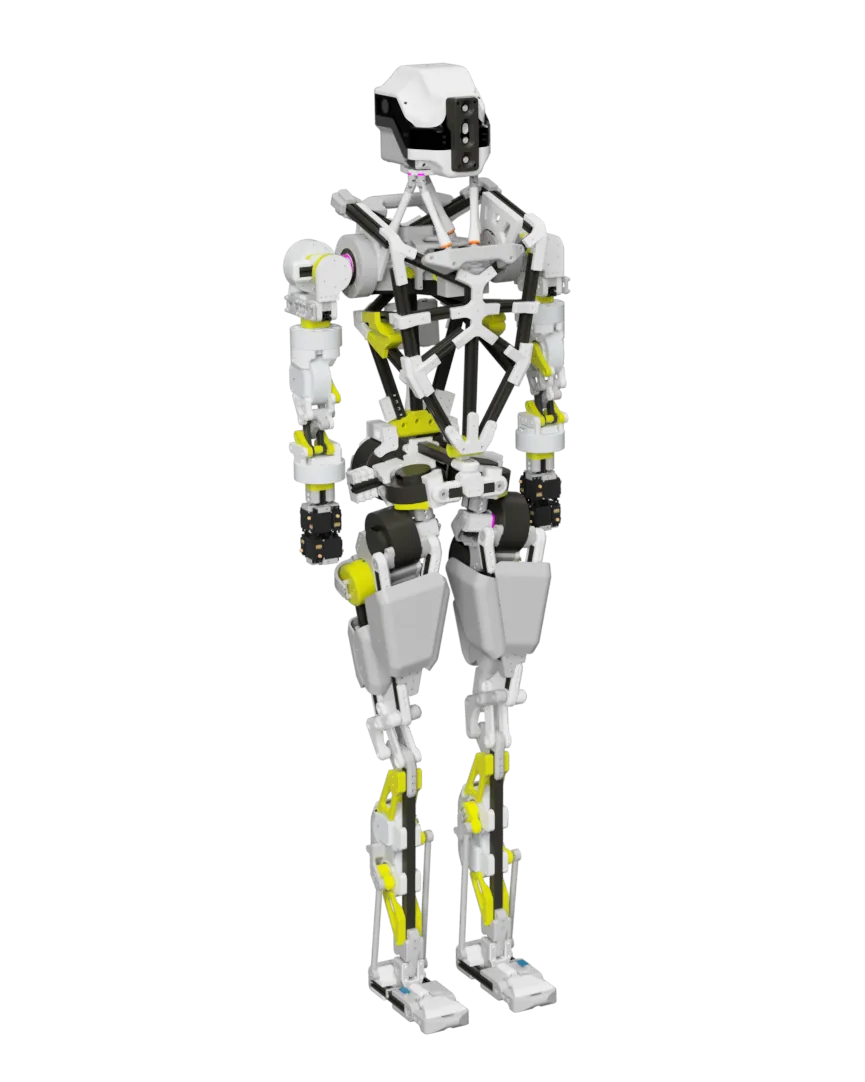
Full-assembly CAD render from dropbear_hardware.Hyperspawn · Hyperspawn · source Simulation, not hardware: 30 s Isaac Lab rollout of the experimental v0.2.0 policy (model_10479.pt) at 50 Hz.Hyperspawn; policy by Hyperspawn Robotics and robit-man (dropbear-locomotion) · CC-BY-NC-SA-4.0 · source 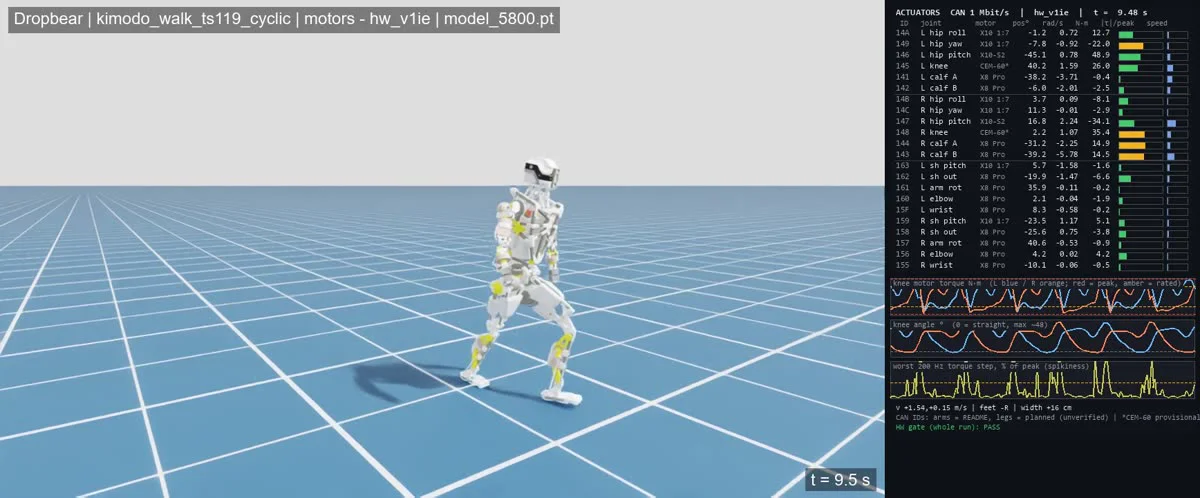
Simulation: deployable walk on the datasheet motor twin (no-state policy, 20 ms target ramp). Hardware gate PASS.Hyperspawn (dropbear-wbc) · PolyForm-Noncommercial-1.0.0 · source 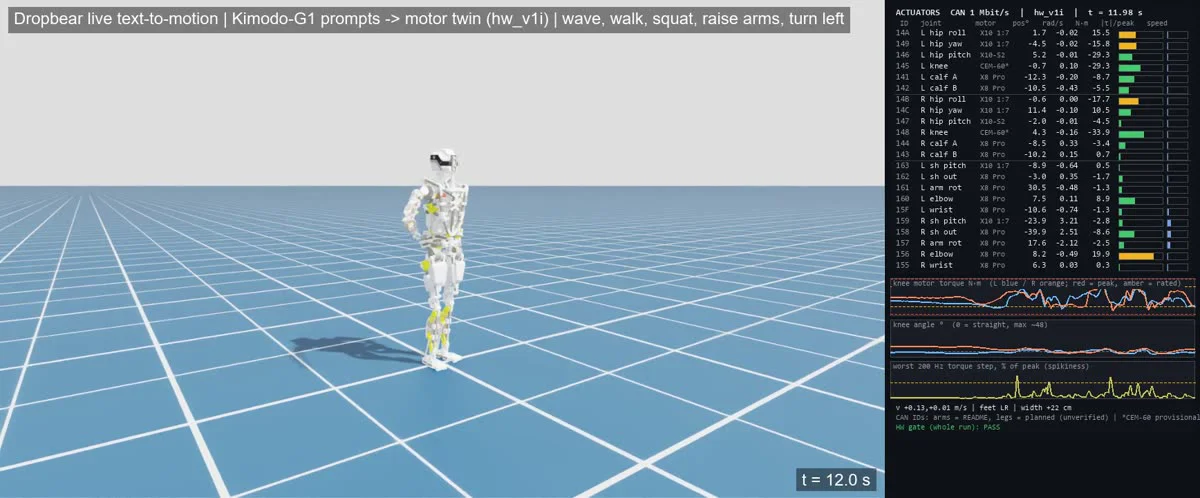
Simulation: live text to motion. A typed prompt, generated by Kimodo, played on the motor twin.Hyperspawn (dropbear-wbc) · PolyForm-Noncommercial-1.0.0 · source 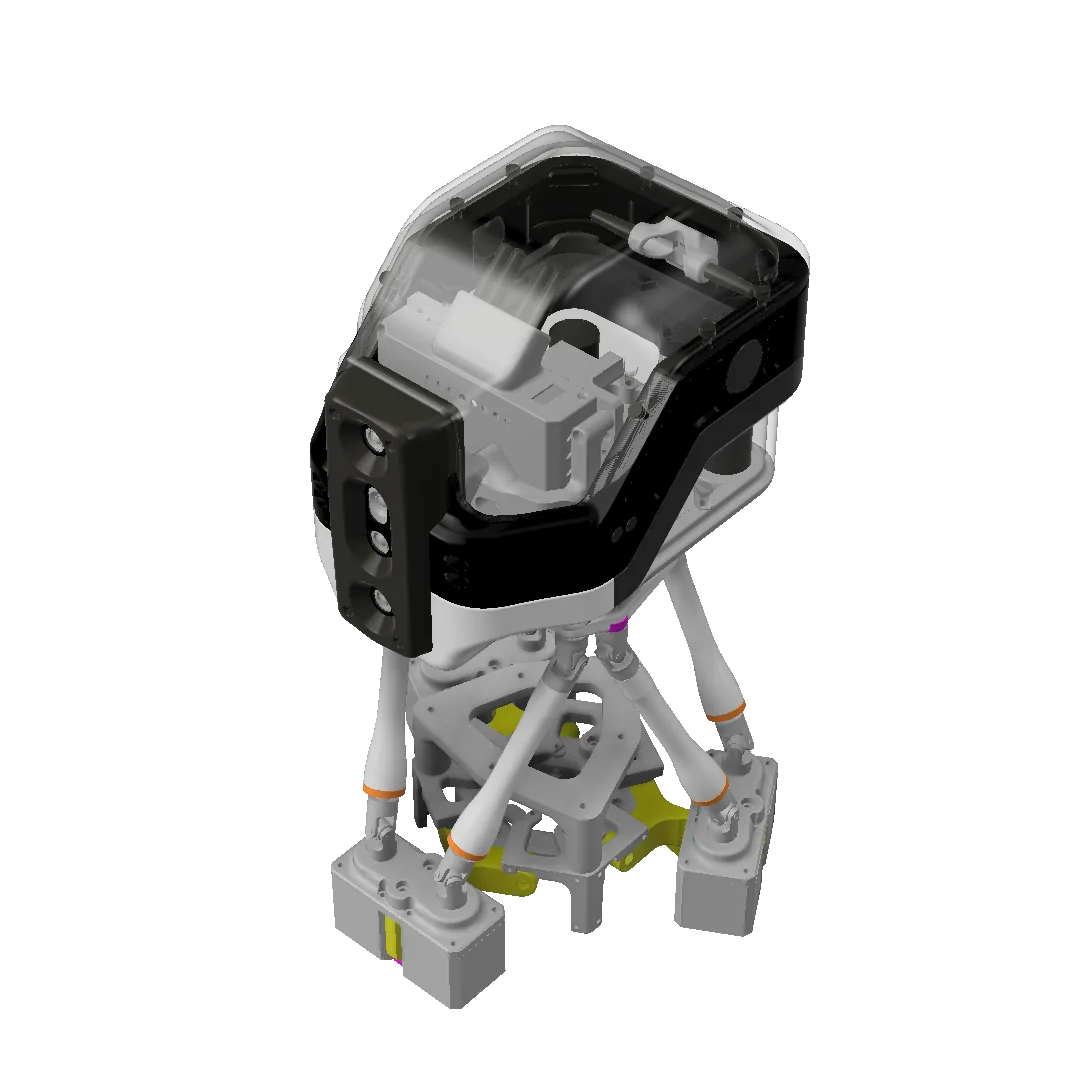
Head and Stewart-platform neck subassembly (six NEMA 17 lead-screw legs).Hyperspawn · Hyperspawn · source
+10 more on humanoidrobots.systems/hyperspawn/dropbear
Recorded rollouts in the viewport
- What
- Physics rollouts recorded in Isaac Lab on Dropbear's datasheet motor twin (27 loop-closure joints solved by PhysX), replayed frame by frame. Nothing is simulated in your tab in this mode; the torque bars are the recorded motor loads.
- Source
- Hyperspawn/dropbear-wbc · Hugging Face · original demo
- License
- PolyForm Noncommercial 1.0.0 · Hyperspawn · dropbear-wbc
- Clips
- Deployable walk · 20 s · 443 KBKimodo G1 walk, Froude-timed, all hardware penalties, smoothed actions
- Live text to motion · 70 s · 1.0 MB5 typed prompts, generated by Kimodo and played on the motor twin in real time
- Generated wave · 6 s · 121 KBhardware gate FAIL: why the elbow is Dropbear's weak spot
- First live generation · 16 s · 323 KBwave, then walk: two Kimodo clips spliced live
- Download
- 1.5 MB before it moves (meshopt GLB 1.1 MB + deployable walk 443 KB), gzip, from Hyperspawn's media store
- Live mode
- “Live physics” runs dropbear-wbc's serial MuJoCo model in the tab (22 joints, the closed loops collapsed into the joints that drive them) and draws this same CAD on it, every linkage posed from the joint state. It holds a stand under our PD controller; it does not walk.
Provenance
- Model
- Dropbear
- Commit
- dba8cd0457ce
- Entry
- data/robot/dropbear_serial.xml
- Files
- 1 · 23 KB, fetched from vtv7xitynucitt4l.public.blob.vercel-storage.com, cached in your browser
- License
- PolyForm Noncommercial 1.0.0
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Caveat
- Live physics on dropbear-wbc's serial model: 22 joints, the knee and elbow four-bars and the parallel ankle collapsed into the joints that drive them, masses from the CAD, datasheet motor limits. Drawn with the full CAD, every linkage posed from the joint state. It holds a stand under our PD controller; it does not walk. The walking you see by default is a recorded Isaac Lab rollout.
- Note
- dropbear-wbc's serial model (dropbear_serial.xml) with the datasheet motor twin, flat soles and a stand keyframe; drawn with the 1.2 MB colored CAD GLB, every linkage posed from the joint state. Hosted on Hyperspawn's media store.
Policies listed for Dropbear
- source
walk, flat ground (v0.1.0, validated in sim)
Isaac Lab + RSL-RL PPO · not replayed in the tab: trained in Isaac Lab on the full Dropbear USD (closed loops, 22 motors in motor space) with its own actuator groups and COM-guided observations. The tab runs the serial model, whose joints are the semantic angles, so its contract cannot be reproduced here
- source
walk over low obstacles (v0.2.0, experimental)
Isaac Lab + RSL-RL PPO · not replayed in the tab: trained in Isaac Lab on the full Dropbear USD (closed loops, 22 motors in motor space) with its own actuator groups and COM-guided observations. The tab runs the serial model, whose joints are the semantic angles, so its contract cannot be reproduced here
Train on GPUs
mjlab ships no stock task for Dropbear. The training page gives you the pinned model and the steps to write a robot config.