Starting viewport
RoboParty (Shanghai RoboParty Technology) · humanoid
ROBOTO_ORIGIN
Fully open-source DIY running/jumping humanoid prototype whose structure, electronics, training and deployment code are all published; buildable from Taobao parts and JLC prototyping.
Frames · ROBOTO_ORIGIN
4 items · credit and license on each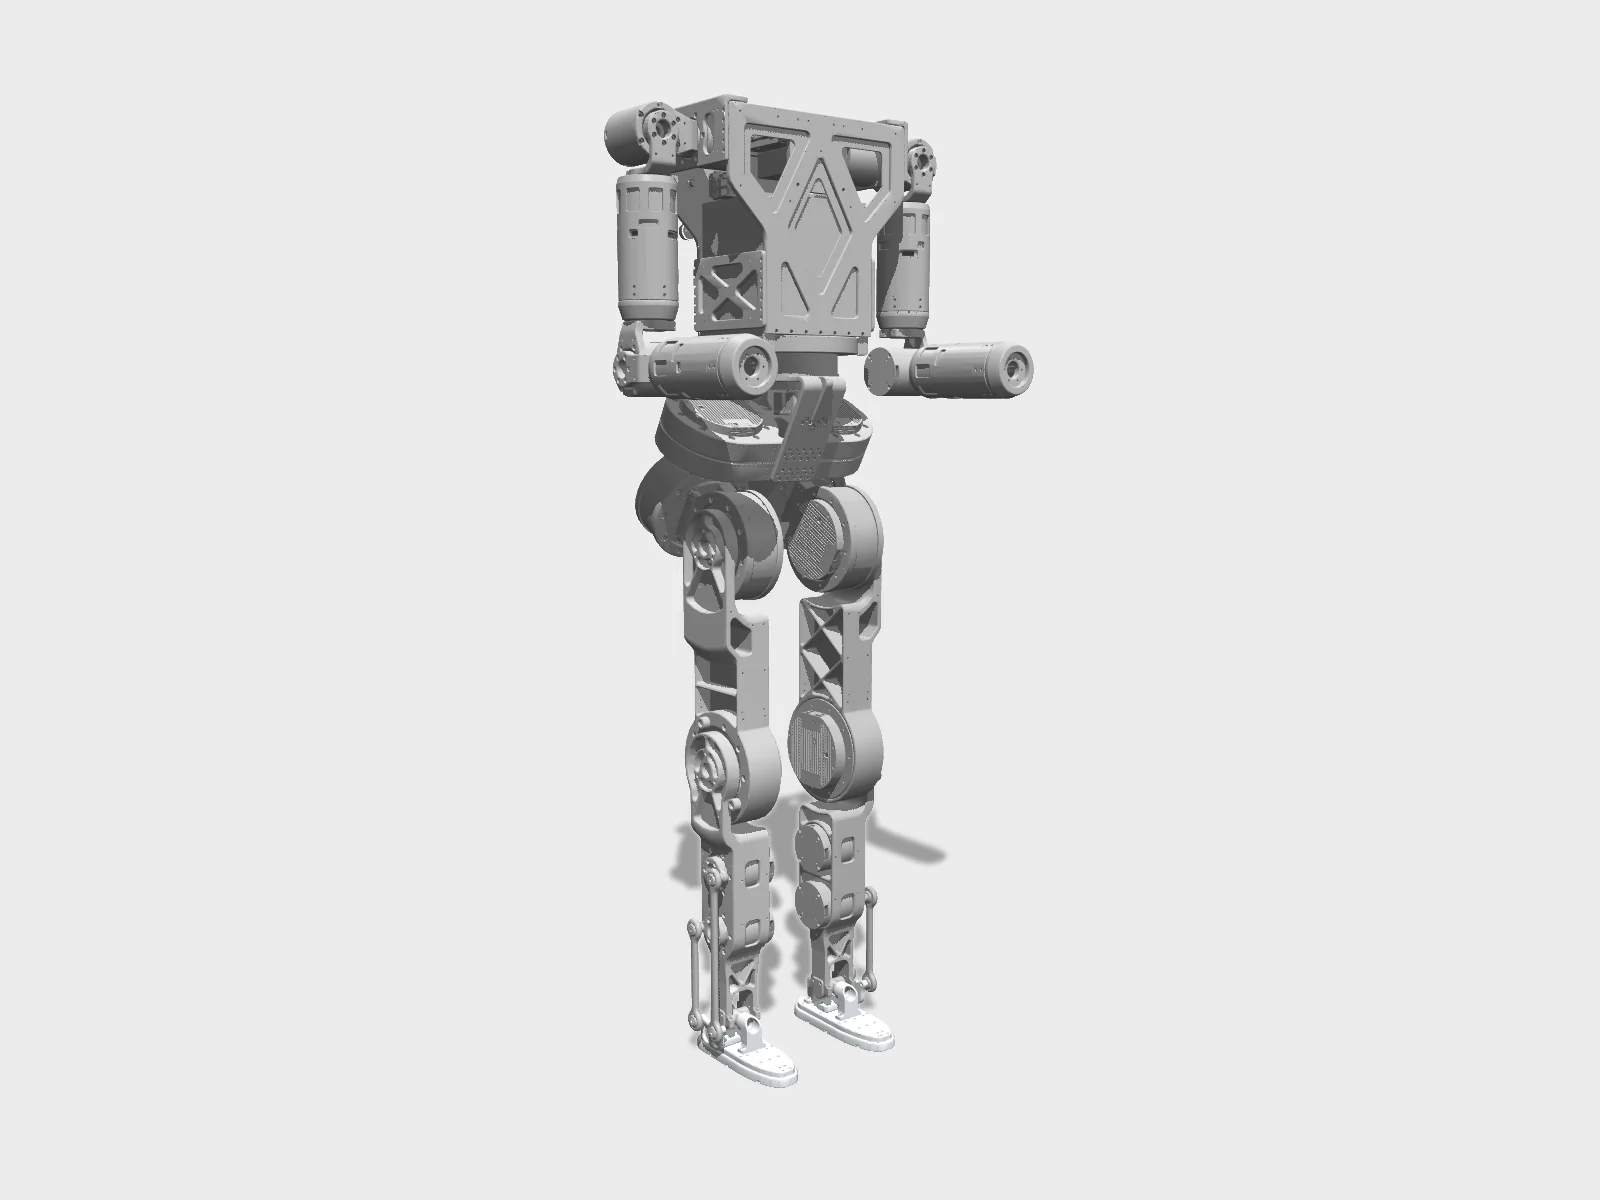
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from Roboparty/roboto_origin (GPL-3.0) · Hyperspawn render · source 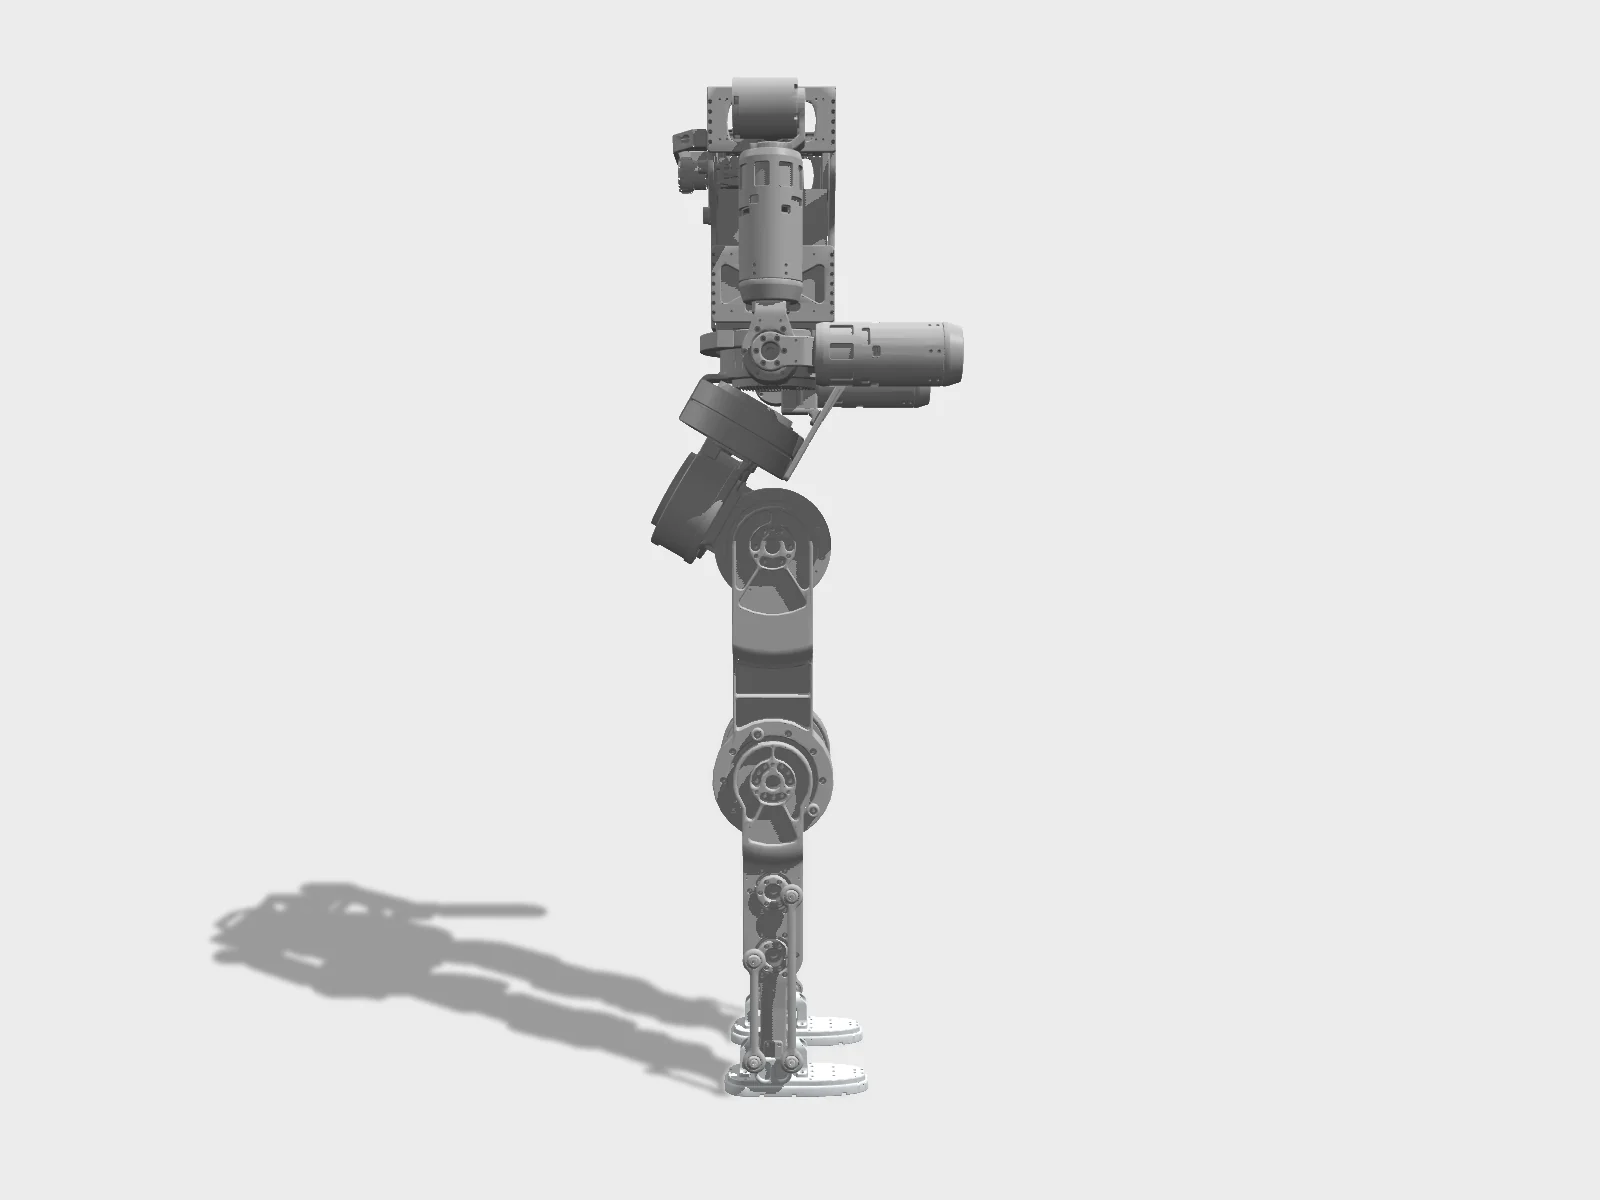
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from Roboparty/roboto_origin (GPL-3.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from Roboparty/roboto_origin (GPL-3.0) · Hyperspawn render · source 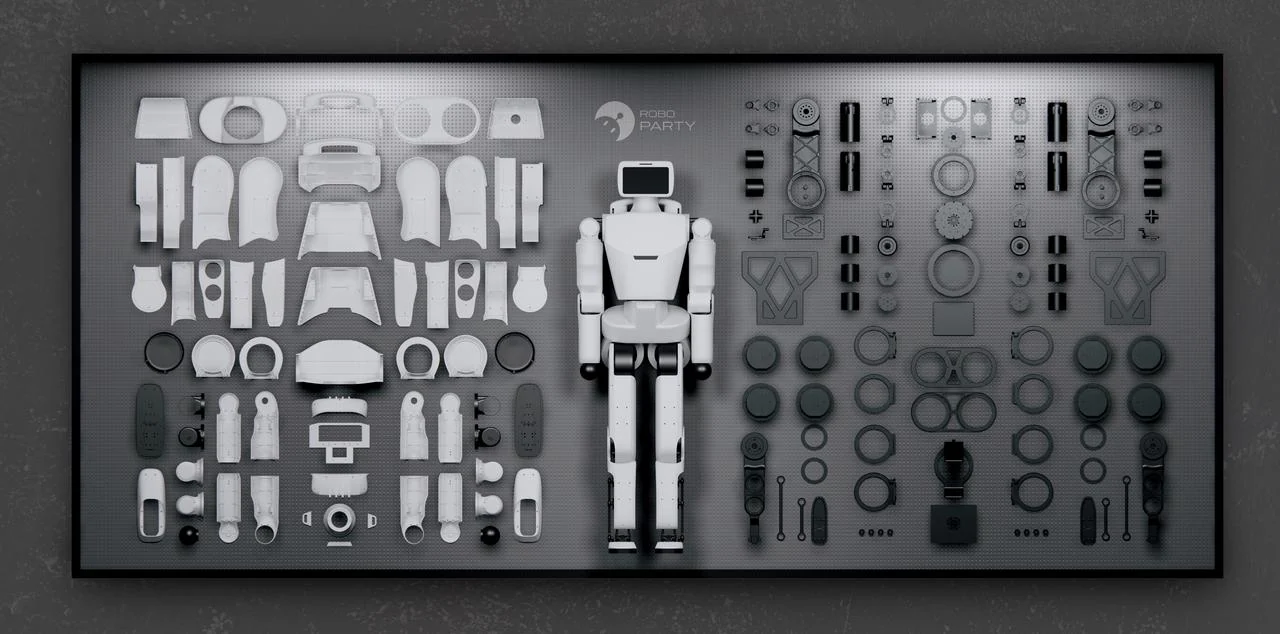
Flat-lay of printed and machined parts, from the roboto_origin README.Roboparty (roboto_origin) · GPL-3.0 · source

Provenance
- Model
- Roboto Origin
- Commit
- c71fd9287d28
- Entry
- modules/rpo_description/mjcf/rpo.xml
- Files
- 25 · 30 MB, fetched from raw.githubusercontent.com, cached in your browser
- License
- GPL-3.0
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Note
- Its <size njmax=5000> asks MuJoCo for more than the 2 GB WebAssembly heap; the tab drops that line and lets MuJoCo size memory itself.
Policies listed for ROBOTO_ORIGIN
- source
walk (default velocity-tracking policy)
Isaac Lab + RSL-RL (roboparty_train), ONNX via roboparty_inference · ONNX published; contract not yet reproduced and tested here
- source
walk, AMP style
Isaac Lab + RSL-RL AMP · ONNX published; contract not yet reproduced and tested here
- source
walk, attention encoder
Isaac Lab + RSL-RL · ONNX published; contract not yet reproduced and tested here
- source
motion tracking: wave / dance (BeyondMimic)
Isaac Lab BeyondMimic · ONNX published; contract not yet reproduced and tested here
- source
get up from the ground
Isaac Lab BeyondMimic-style motion tracking · ONNX published; contract not yet reproduced and tested here
- source
interruptible walking
Isaac Lab + RSL-RL · ONNX published; contract not yet reproduced and tested here
- source
parkour with depth
Isaac Lab + RSL-RL · ONNX published; contract not yet reproduced and tested here
Train on GPUs
mjlab ships no stock task for ROBOTO_ORIGIN. The training page gives you the pinned model and the steps to write a robot config.