Starting viewport
Fourier (Fourier Intelligence) · humanoid
Fourier N1
1.3 m, 38 kg humanoid launched April 2025 with open-released BOM, design drawings, assembly guides and base software.
Frames · Fourier N1
4 items · credit and license on each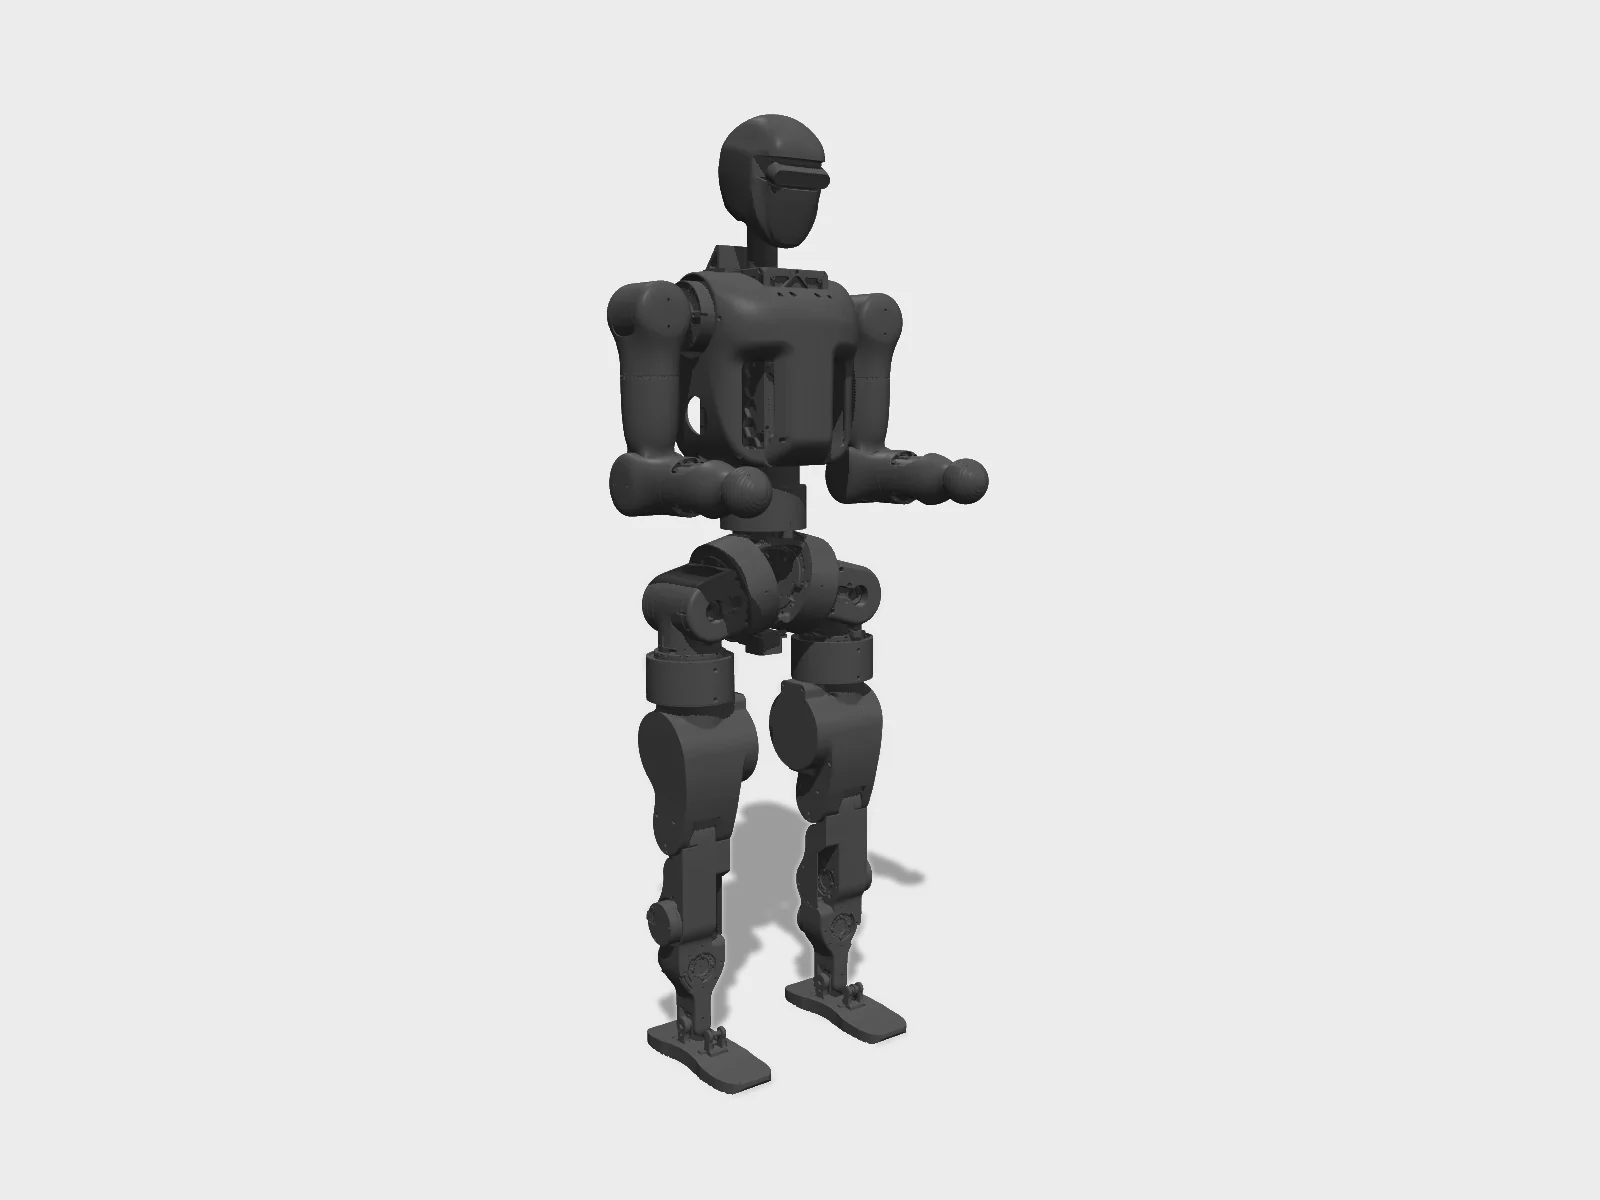
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/fourier_n1 (Apache-2.0) · Hyperspawn render · source 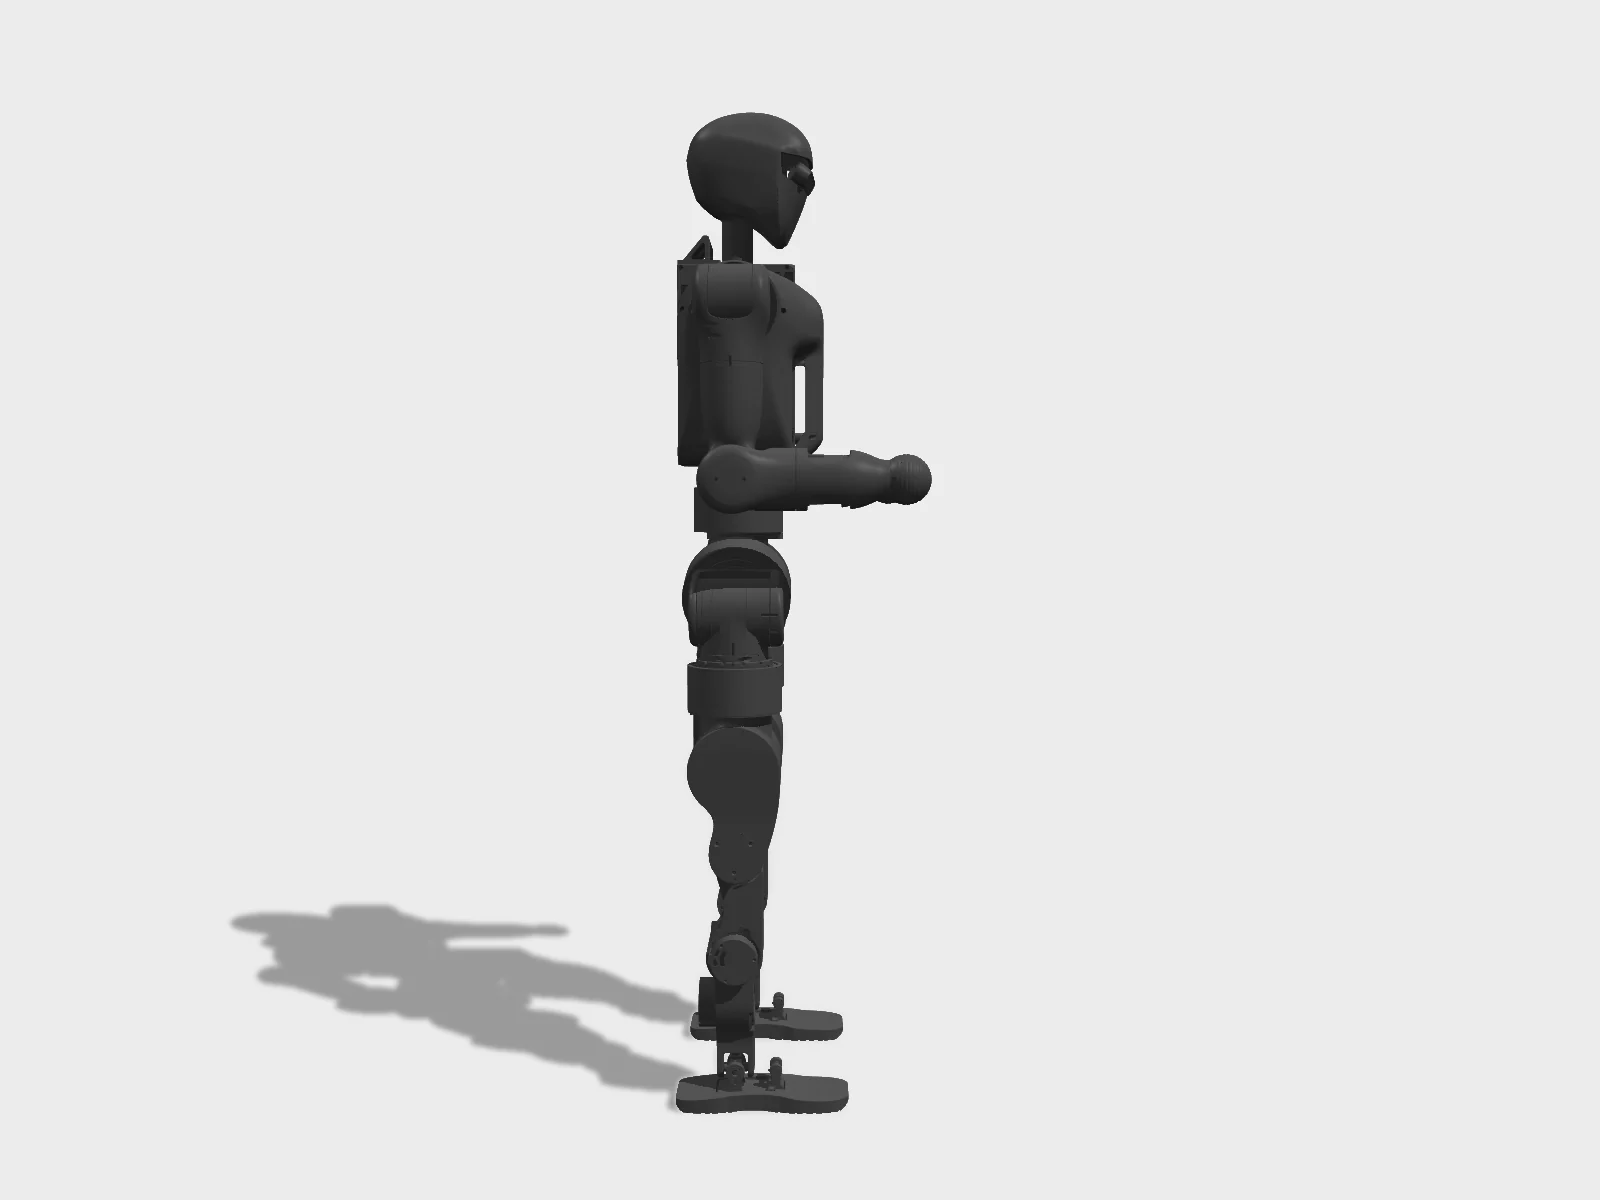
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/fourier_n1 (Apache-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/fourier_n1 (Apache-2.0) · Hyperspawn render · source Fourier N1 | Street Dance BotFourier · official embed · source
Provenance
- Model
- Fourier N1
- Commit
- c96a32d28fb5
- Entry
- fourier_n1/scene.xml
- Files
- 31 · 61 MB, fetched from raw.githubusercontent.com, cached in your browser
- License
- Apache-2.0
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
Policies listed for Fourier N1
- source
Walk (TorchScript, developer API, radians)
PyTorch JIT (Isaac Gym / legged_gym) · not replayed in the tab
- source
Walk, refined (TorchScript)
PyTorch JIT (Isaac Gym / legged_gym, FourierN1_refine branch of Wiki-GRx-Gym) · not replayed in the tab
- source
Built-in tasks: stand/walk/run (up to 3.5 m/s), get-up front/back, squat, single-leg stand, lie down, box-carry arm pose
fourier-grx (closed binary) · not replayed in the tab
Train on GPUs
mjlab ships no stock task for Fourier N1. The training page gives you the pinned model and the steps to write a robot config.