Starting viewport
Stanford University · humanoid
ToddlerBot
Low-cost, fully 3D-printed open-source small humanoid (0.56 m, 3.4 kg, 30 DOF) for scalable policy learning research.
Frames · ToddlerBot
6 items · credit and license on each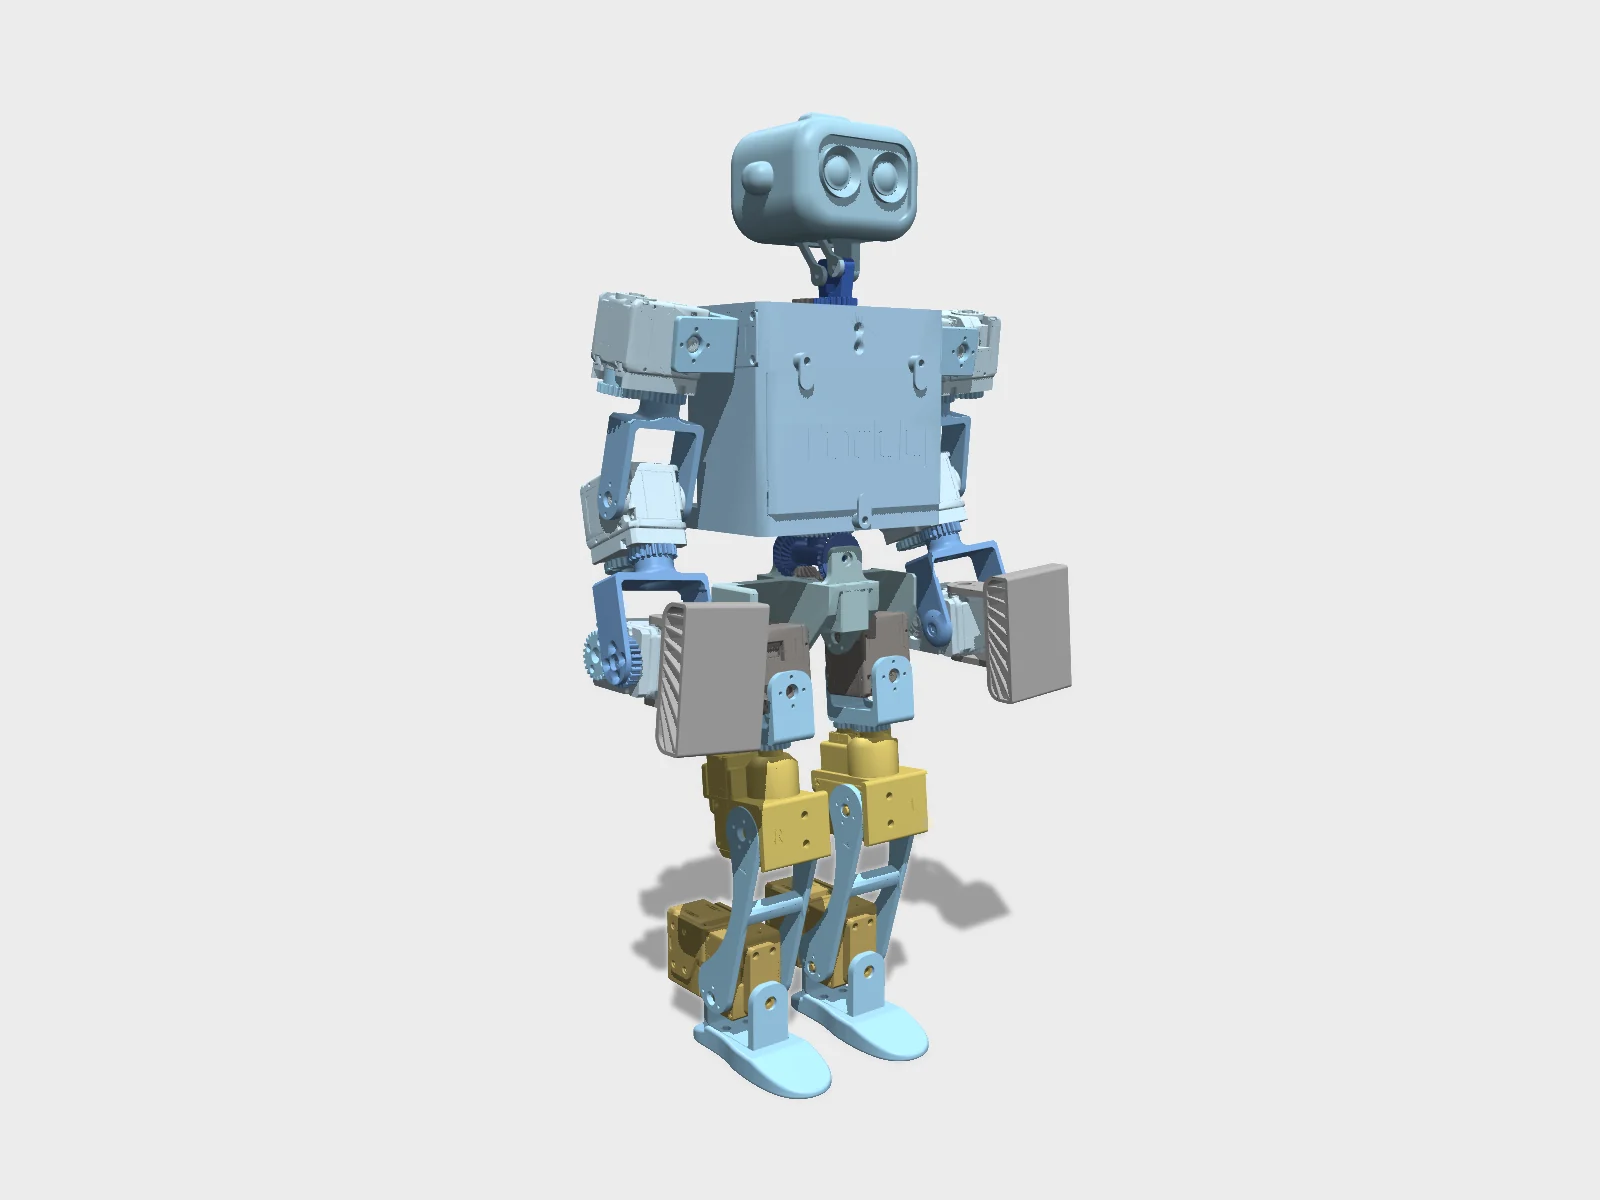
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/toddlerbot_2xc (MIT) · Hyperspawn render · source 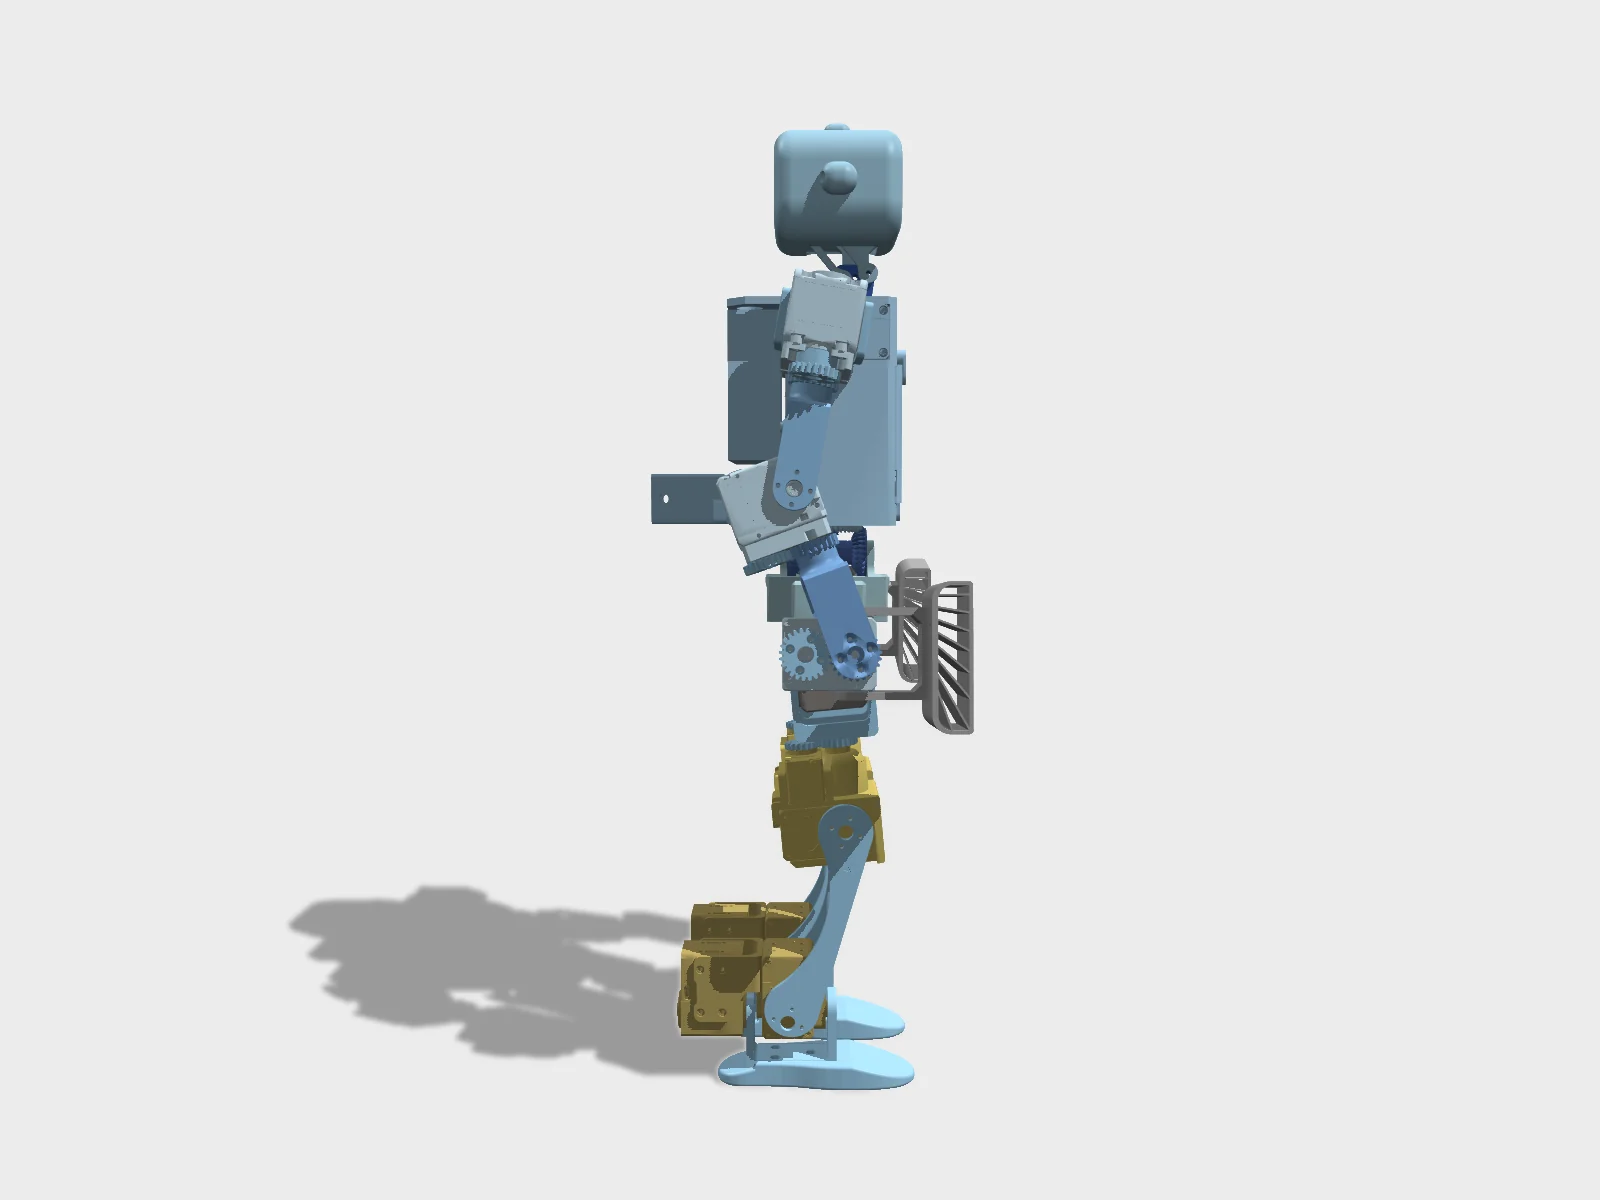
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/toddlerbot_2xc (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/toddlerbot_2xc (MIT) · Hyperspawn render · source 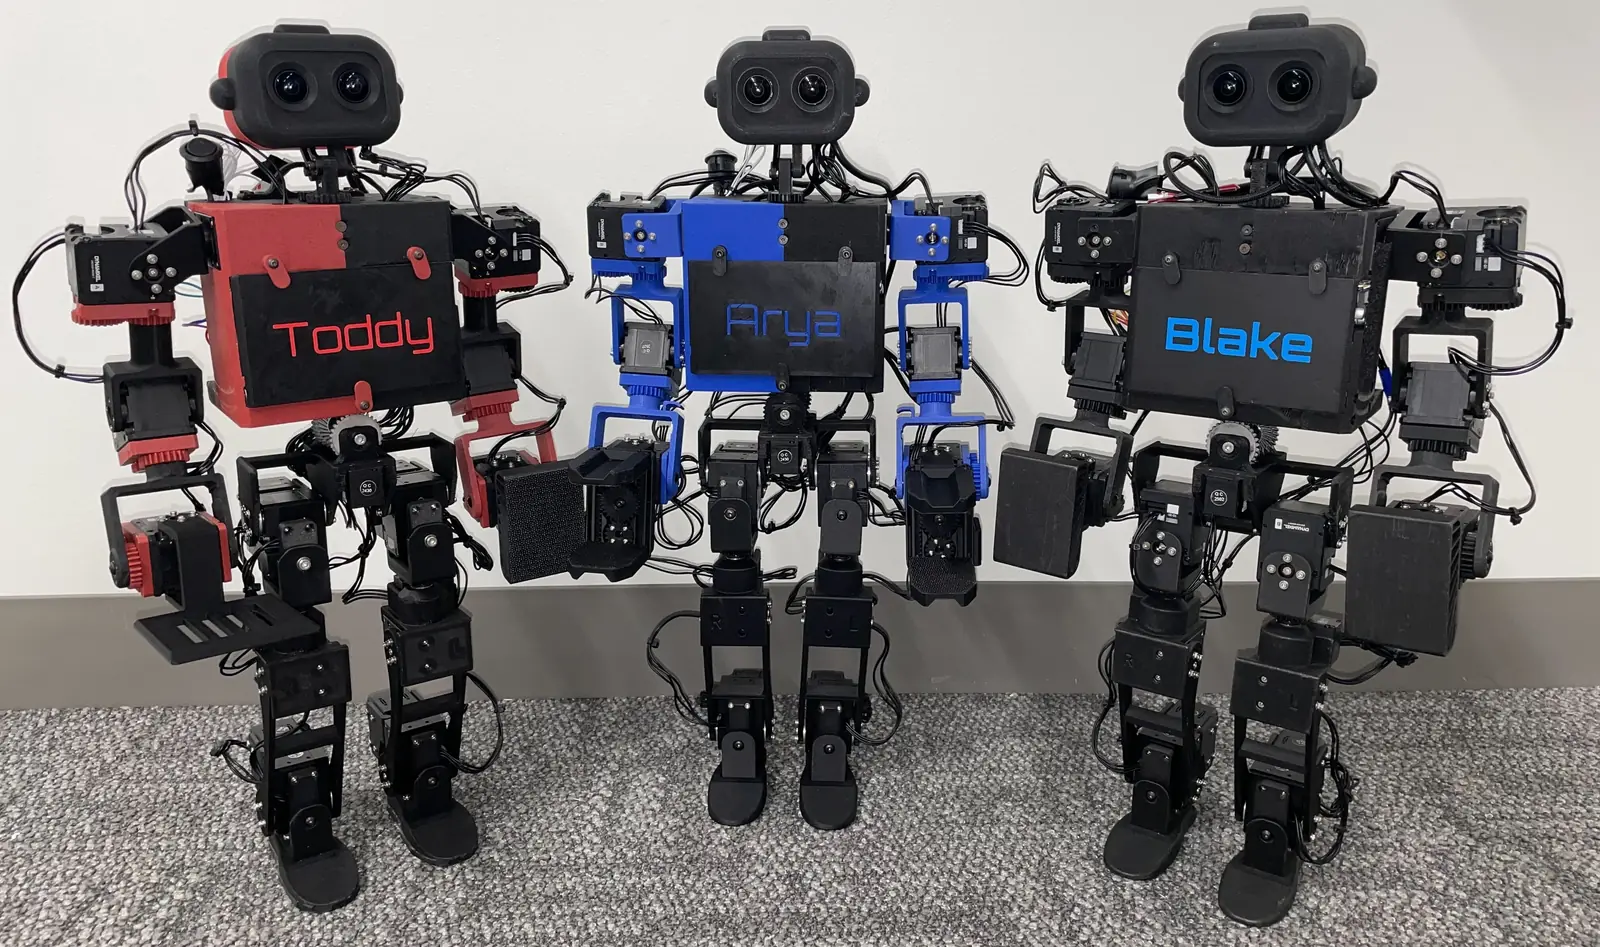
ToddlerBot banner from the project repo.Haochen Shi et al. (ToddlerBot) · MIT · source ToddlerBot: Open-Source ML-Compatible Humanoid Platform for Loco-ManipulationHaochen Shi · official embed · source ToddlerBot 2.0 Arm OverviewHaochen Shi · official embed · source

Provenance
- Model
- ToddlerBot 2XC
- Commit
- c96a32d28fb5
- Entry
- toddlerbot_2xc/scene.xml
- Files
- 49 · 65 MB, fetched from raw.githubusercontent.com, cached in your browser
- License
- MIT
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Caveat
- Loads and runs, but our generic PD stand hold does not keep it up; it needs its own balance controller or a trained policy.
Policies listed for ToddlerBot
- source
walk (omnidirectional, 2XC)
MuJoCo MJX + RSL-RL PPO, ONNX Runtime on Jetson · not replayed in the tab
- source
get up from the ground
MuJoCo MJX + RSL-RL PPO · not replayed in the tab
- source
crawl (full / only / rotate)
MuJoCo MJX + RSL-RL PPO · not replayed in the tab
- source
crawl up / down stairs
MuJoCo MJX + RSL-RL PPO · not replayed in the tab
- source
climb up / down box, climb wall
MuJoCo MJX + RSL-RL PPO · not replayed in the tab
- source
multi-skill whole-body locomotion (Locomotion Beyond Feet)
RL skill policies + depth skill classifier (FoundationStereo) · not replayed in the tab
- source
push-up (keyframe replay)
open-loop keyframe replay (run_policy.py --policy replay) · not replayed in the tab
- source
cartwheel (DeepMimic-style)
MuJoCo MJX + RSL-RL PPO · not replayed in the tab
- source
bimanual manipulation (diffusion policy)
Diffusion Policy (PyTorch) · not replayed in the tab
Train on GPUs
mjlab ships no stock task for ToddlerBot. The training page gives you the pinned model and the steps to write a robot config.