Starting viewport
Chestnut Robotics (formerly TetherIA) · hand
Aero Hand Open
Open-source tendon-driven five-finger hand with 7 actuated DOF (16 joints), fully 3D printed, weighing 389 g, with a Python SDK and ROS2 support.
Frames · Aero Hand Open
6 items · credit and license on each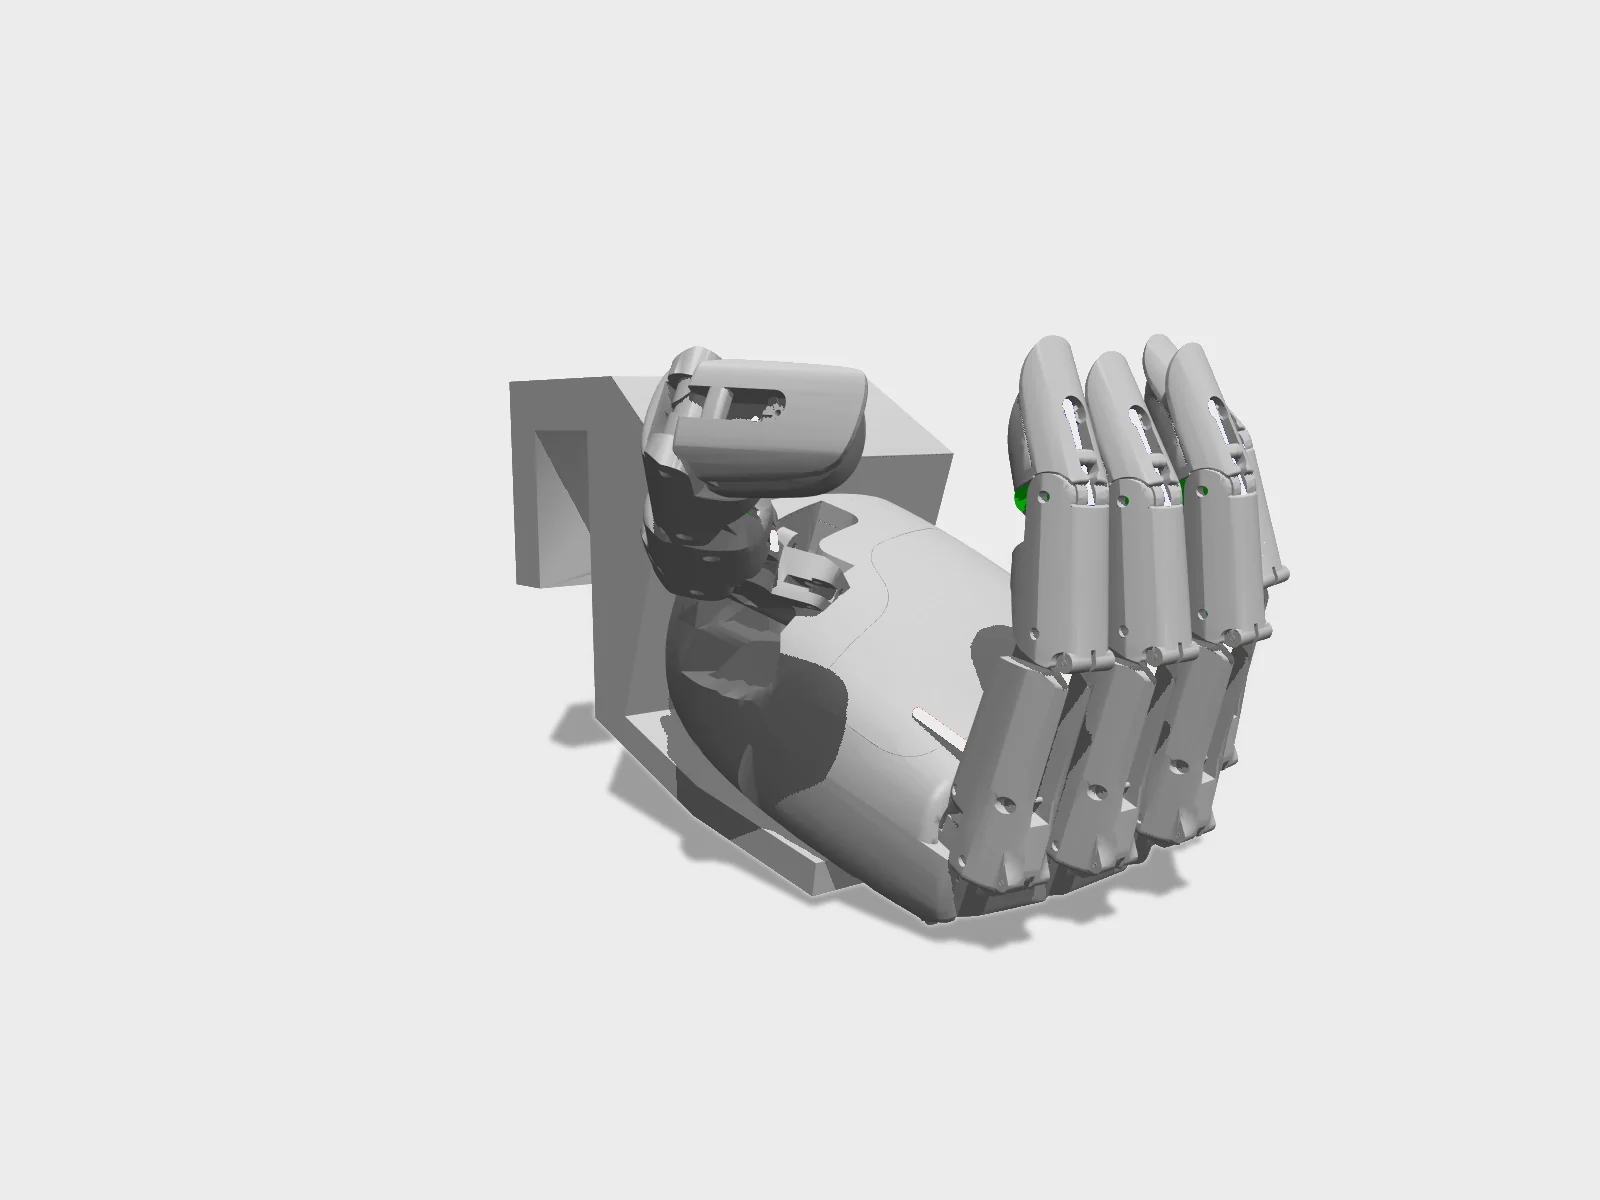
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/tetheria_aero_hand_open (Apache-2.0) · Hyperspawn render · source 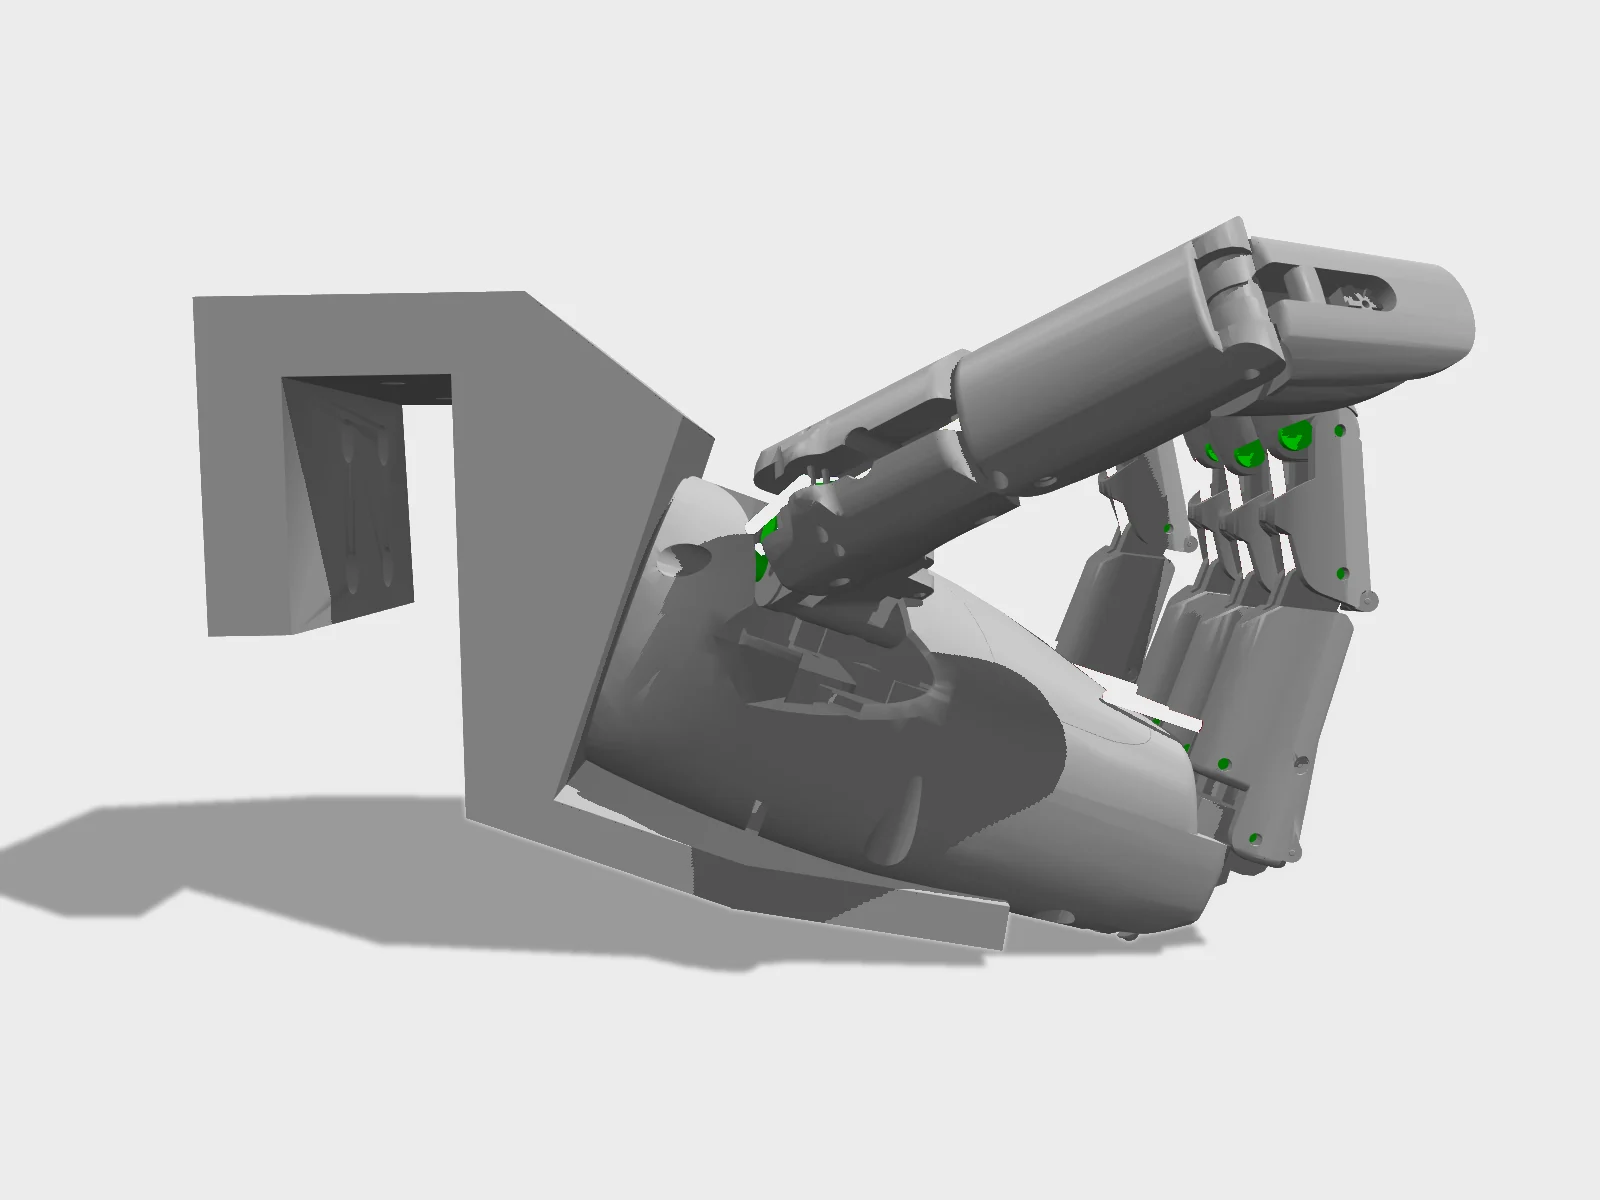
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/tetheria_aero_hand_open (Apache-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/tetheria_aero_hand_open (Apache-2.0) · Hyperspawn render · source 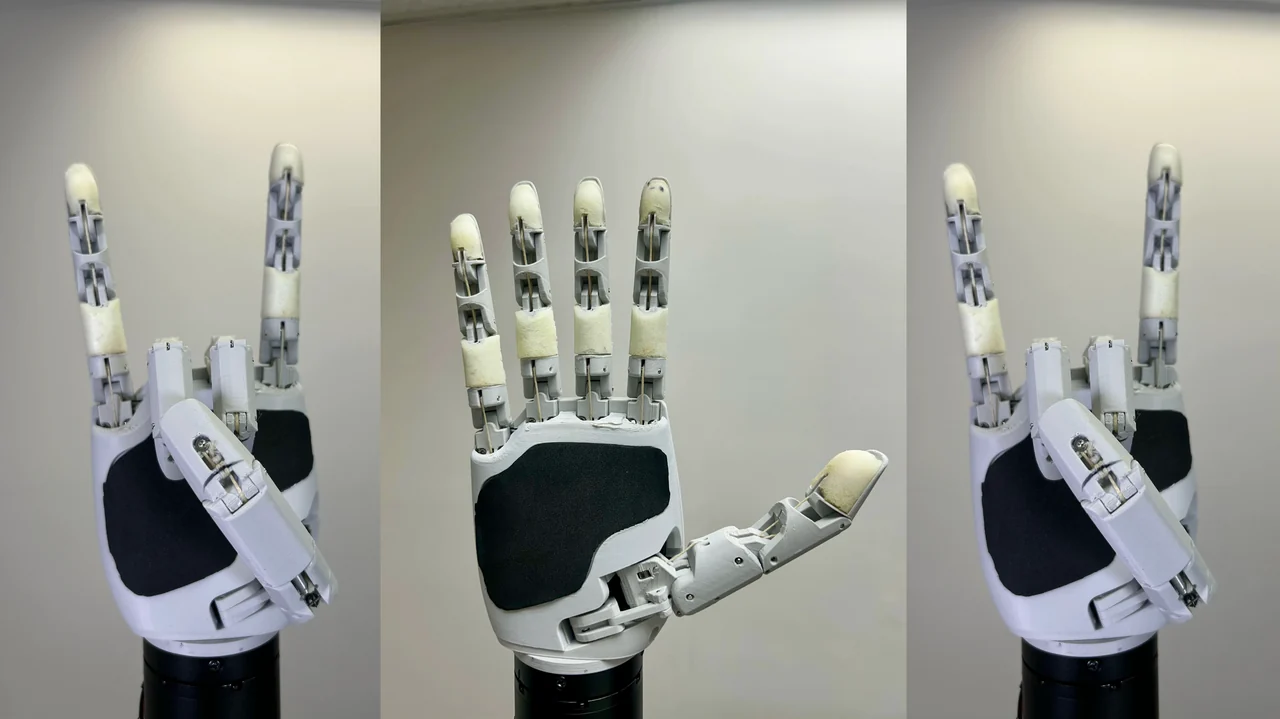
Banner from the aero-hand-open repo.Chestnut Robotics (aero-hand-open) · CC-BY-NC-SA-4.0 · source Introducing Aero Hand Open | TetherIA’s First Open-Source Robotic HandChestnutRobotics · official embed · source Aero Hand Open Lifts a 5-Gallon Water Jug | Open-Source Robotic Hand Strength Test #roboticsChestnutRobotics · official embed · source

Provenance
No browser-ready model packaged yet.
The description is public, but nobody has pinned a commit and checked it compiles in MuJoCo WASM. Clone it and drop the folder on the viewport above (MJCF, or URDF with STL/OBJ meshes). Files stay in your tab.
Policies listed for Aero Hand Open
- source
in-hand cube rotation about Z (60 mm, 117 g cube)
MuJoCo Playground PPO, deployed via ROS 2 (rl_z_rotation_deploy) · not replayed in the tab
Train on GPUs
mjlab ships no stock task for Aero Hand Open. The training page gives you the pinned model and the steps to write a robot config.