Starting viewport
Carnegie Mellon University · hand
LEAP Hand
Low-cost 16-DOF, four-finger anthropomorphic research hand built from Dynamixel servos and readily available parts, assemblable in under 4 hours.
Frames · LEAP Hand
4 items · credit and license on each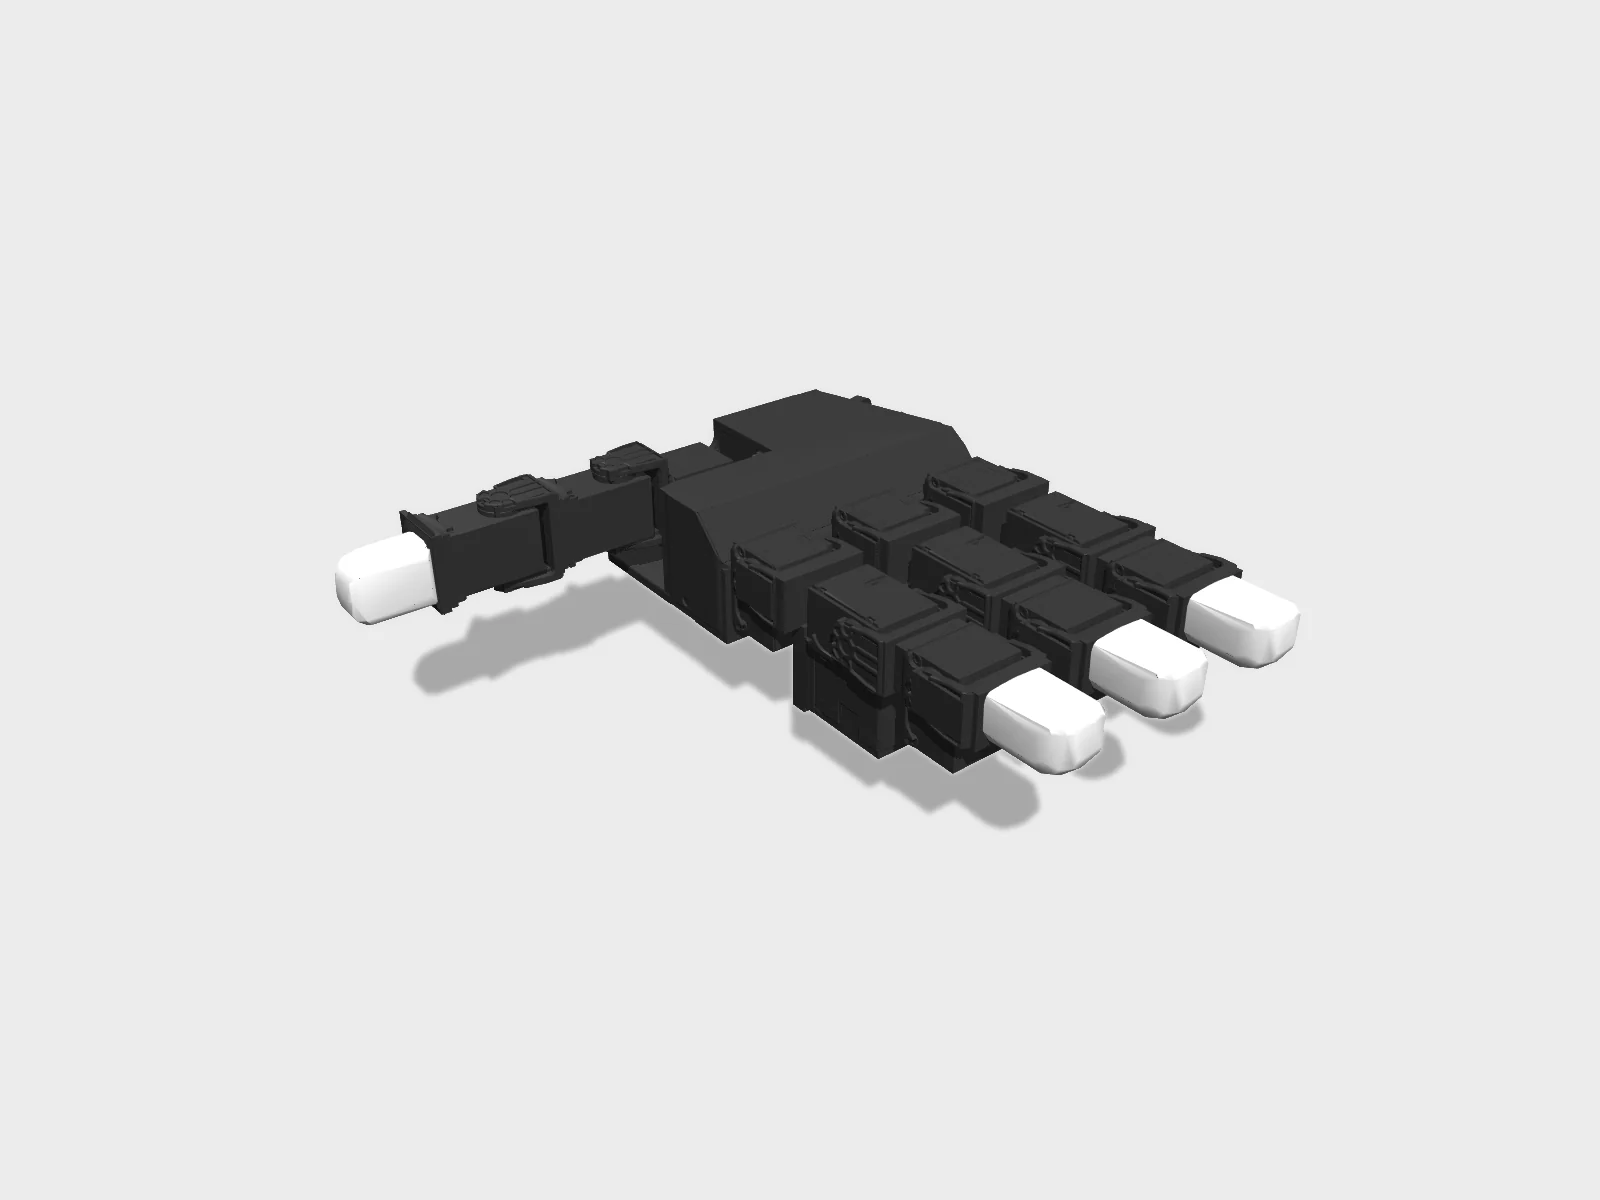
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/leap_hand (MIT) · Hyperspawn render · source 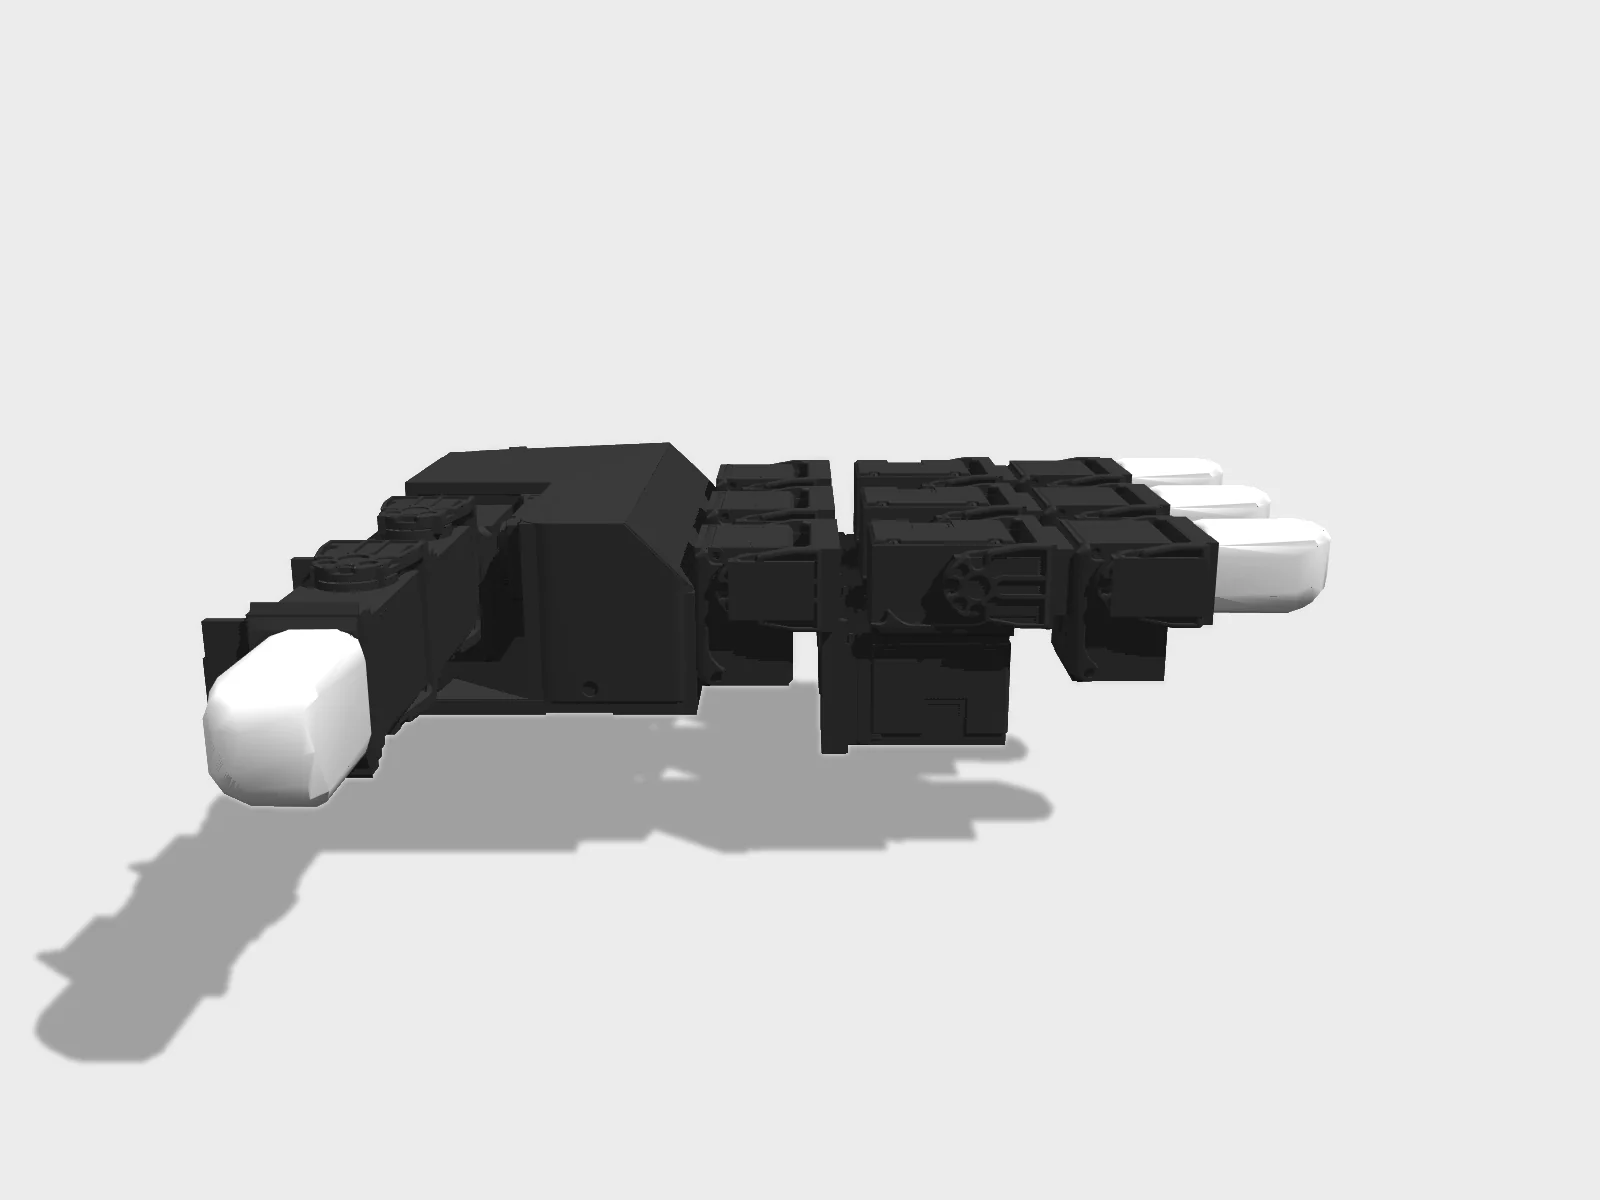
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from mujoco_menagerie/leap_hand (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/leap_hand (MIT) · Hyperspawn render · source LEAP Hand: Low-Cost, Anthropomorphic, Multi-fingered Hand [RSS 2023]Deepak Pathak · official embed · source
Provenance
No browser-ready model packaged yet.
The description is public, but nobody has pinned a commit and checked it compiles in MuJoCo WASM. Clone it and drop the folder on the viewport above (MJCF, or URDF with STL/OBJ meshes). Files stay in your tab.
Policies listed for LEAP Hand
- source
in-hand cube reorientation (LeapHandRot)
Isaac Gym Preview 4 + rl_games PPO (LEAP_Hand_Sim) · not replayed in the tab
Train on GPUs
mjlab ships no stock task for LEAP Hand. The training page gives you the pinned model and the steps to write a robot config.