Starting viewport
Duke University General Robotics Lab · biped
Duke Humanoid v1
Open-source 10-DOF research biped for energy-efficient RL locomotion exploiting passive dynamics.
Frames · Duke Humanoid v1
2 items · credit and license on each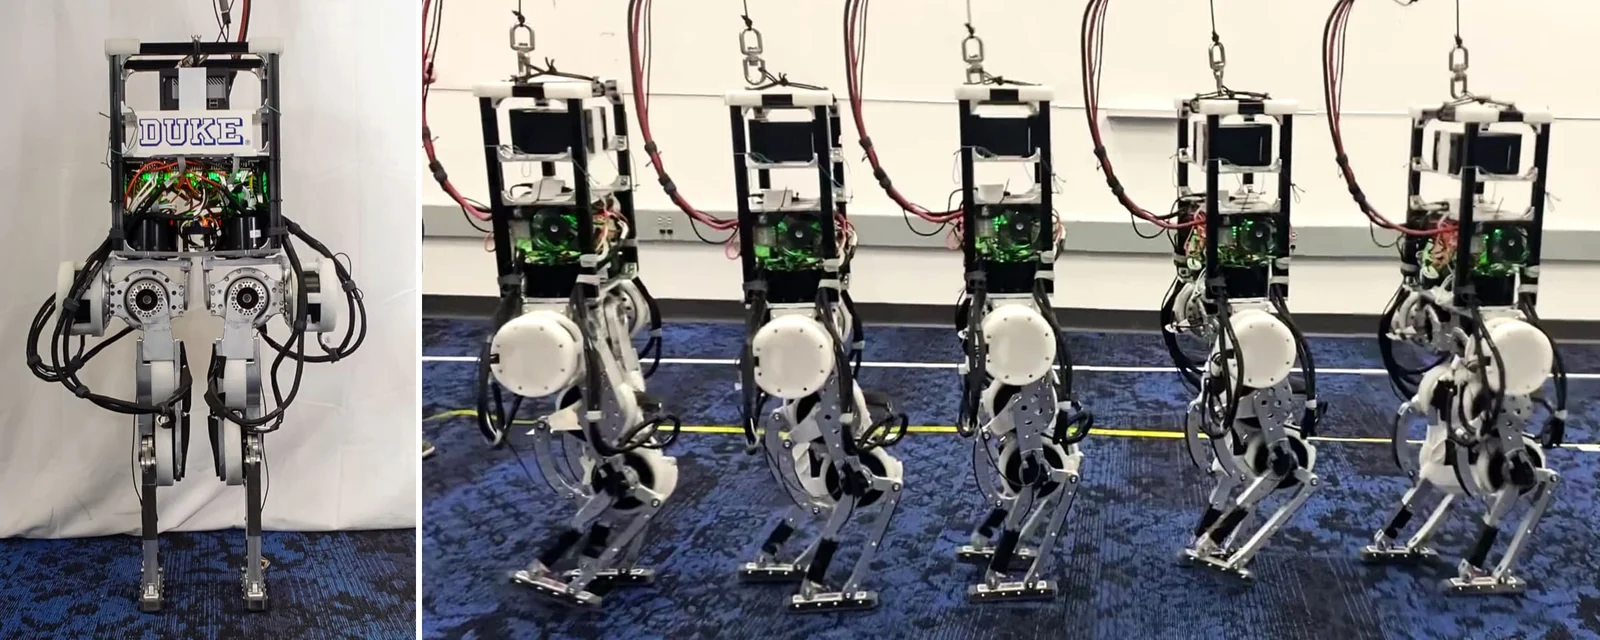

Provenance
No browser-ready model packaged yet.
The description is public, but nobody has pinned a commit and checked it compiles in MuJoCo WASM. Clone it and drop the folder on the viewport above (MJCF, or URDF with STL/OBJ meshes). Files stay in your tab.
Policies listed for Duke Humanoid v1
- source
walk, velocity tracking (baseline)
Isaac Gym + rl_games (legged_env) · ONNX published; contract not yet reproduced and tested here
- source
walk, energy-efficient passive-dynamics policy
Isaac Gym + rl_games (legged_env) · ONNX published; contract not yet reproduced and tested here
- source
walk (training checkpoints)
Isaac Gym + rl_games · not replayed in the tab
Train on GPUs
mjlab ships no stock task for Duke Humanoid v1. The training page gives you the pinned model and the steps to write a robot config.