Starting viewport
SIGRobotics UIUC / Hugging Face LeRobot · rover
LeKiwi
Low-cost mobile manipulator combining a three-omni-wheel holonomic base with an SO-101 arm, a Raspberry Pi 5 and two RGB cameras, supported in LeRobot.
Frames · LeKiwi
4 items · credit and license on each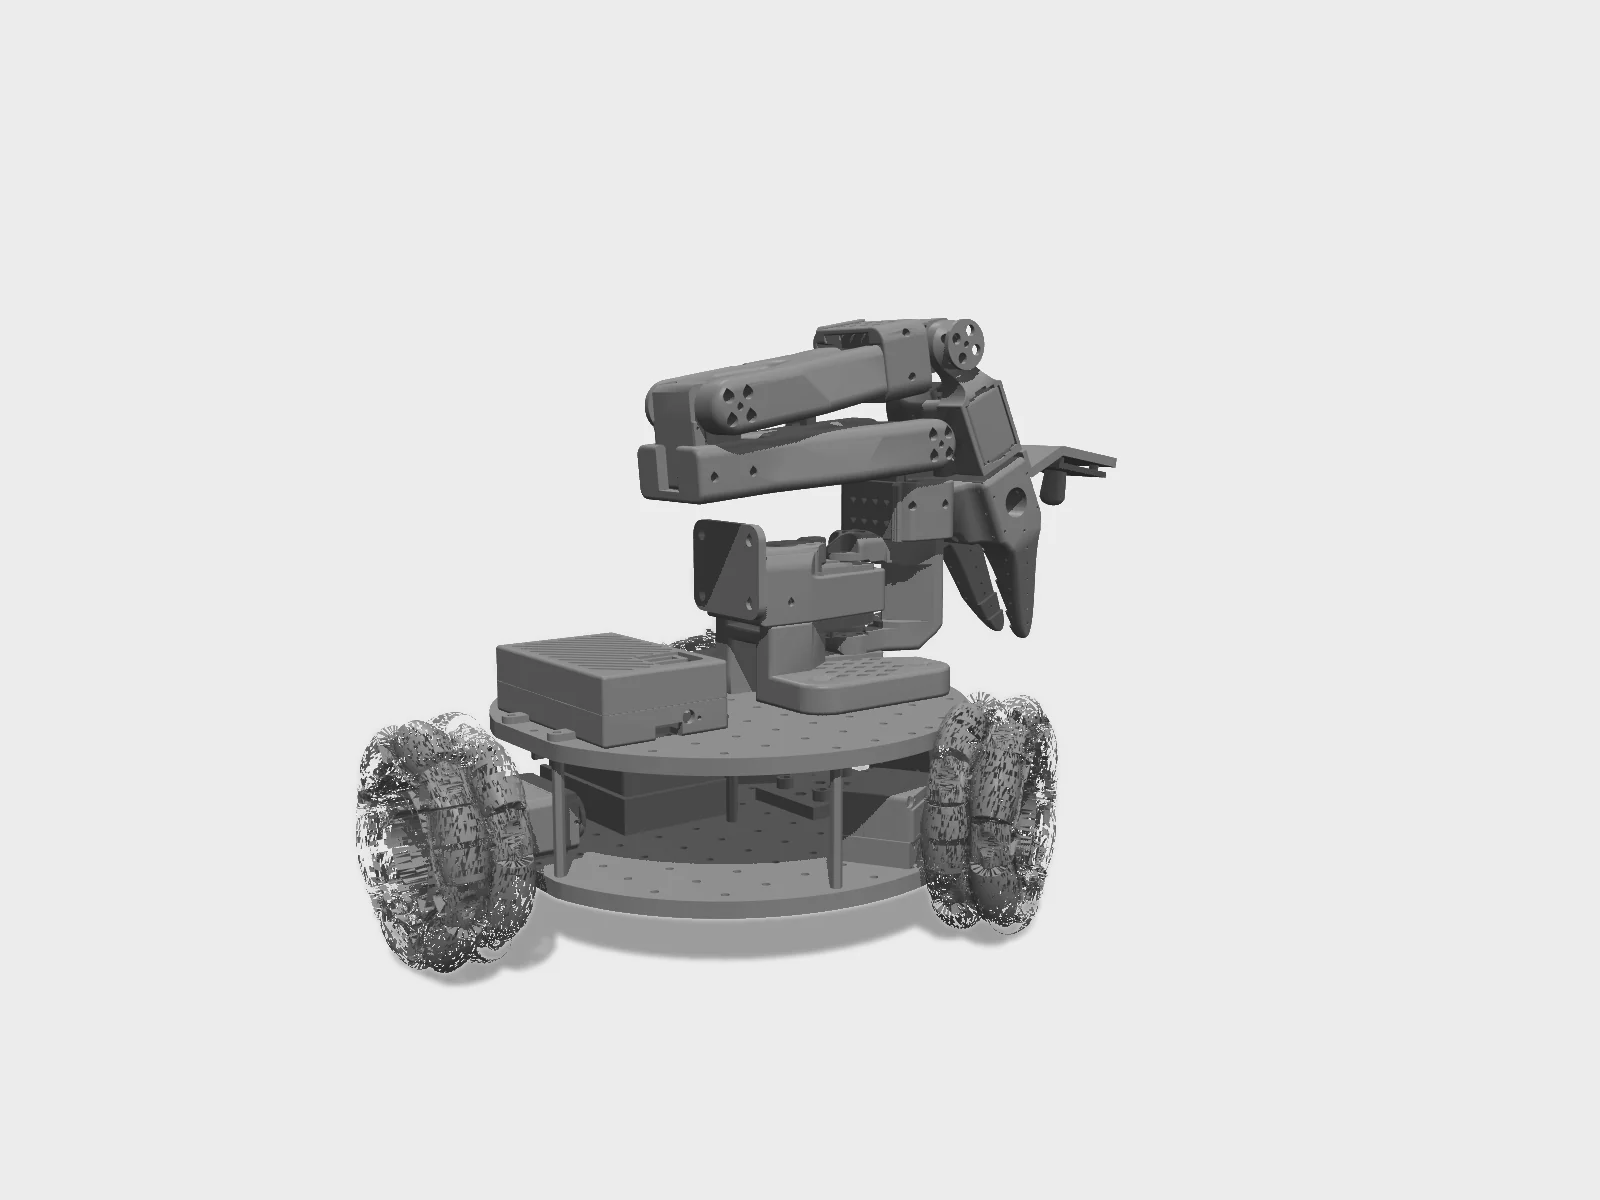
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from SIGRobotics-UIUC/LeKiwi (Apache-2.0) · Hyperspawn render · source 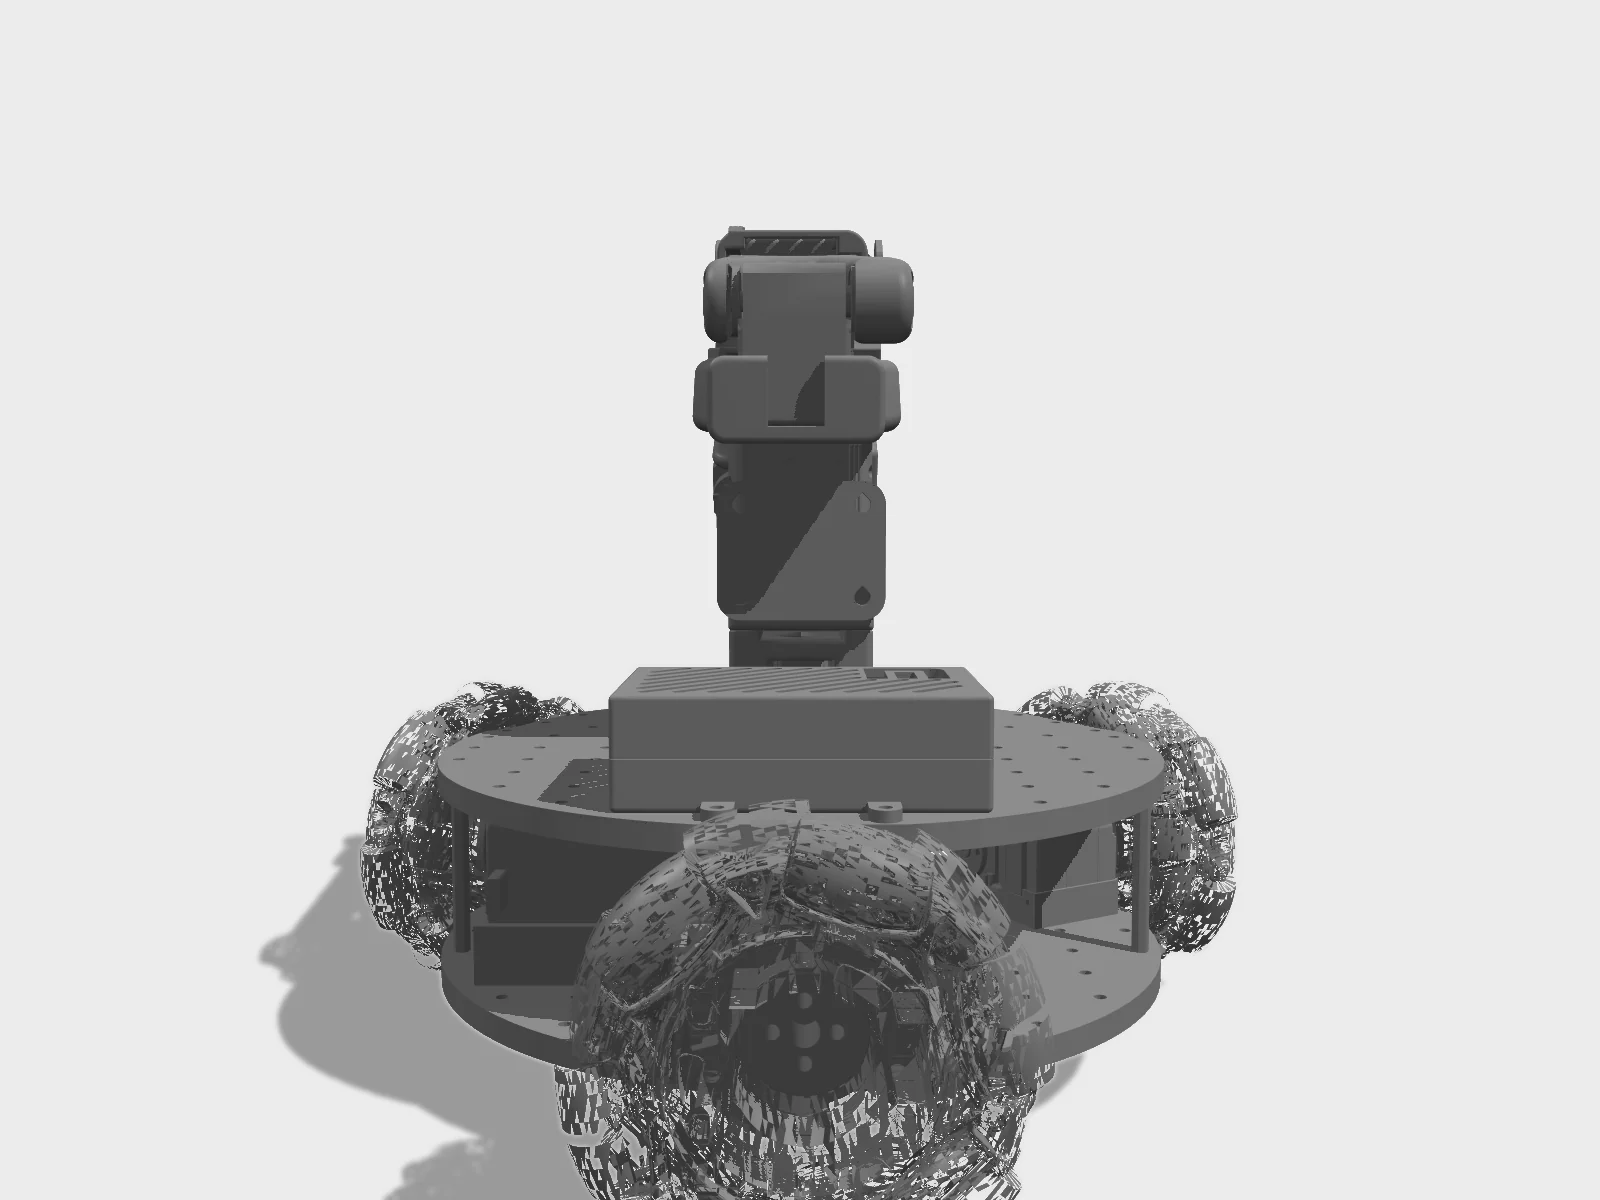
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from SIGRobotics-UIUC/LeKiwi (Apache-2.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from SIGRobotics-UIUC/LeKiwi (Apache-2.0) · Hyperspawn render · source 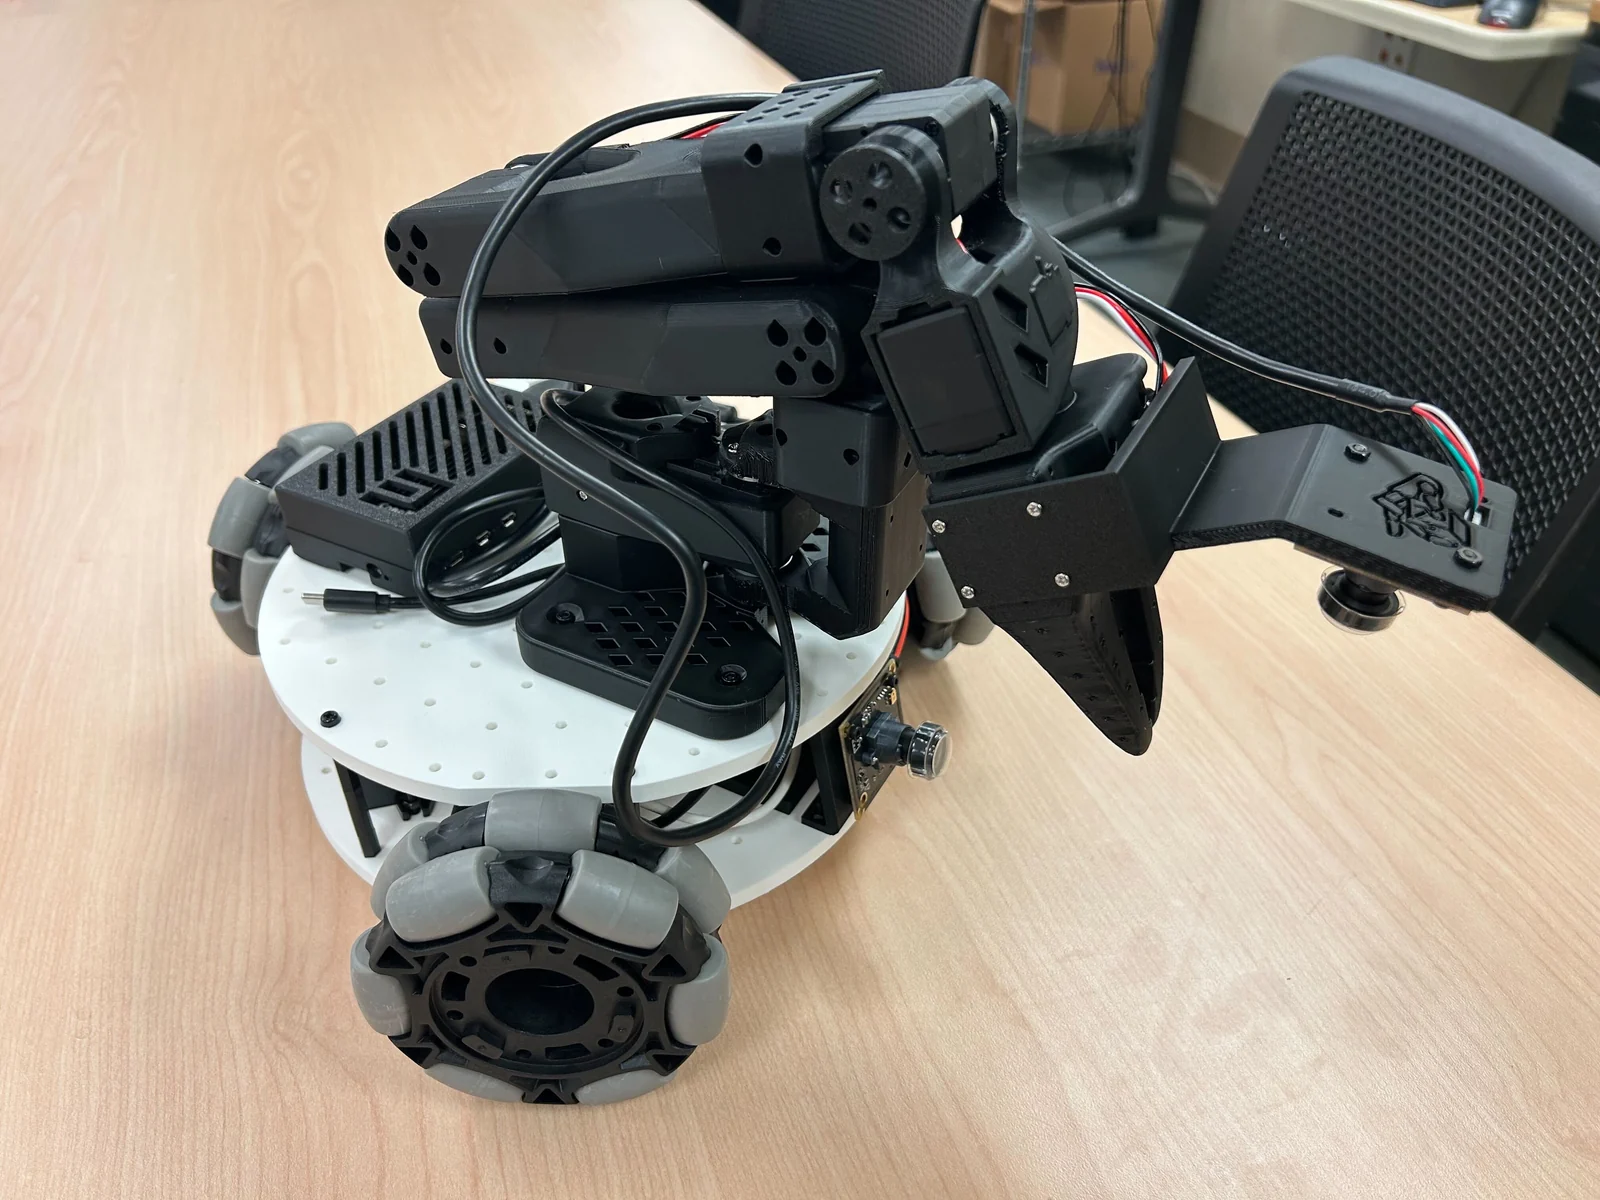
Real build, from the LeKiwi README.SIGRobotics UIUC (LeKiwi) · Apache-2.0 · source

Provenance
No browser-ready model packaged yet.
The description is public, but nobody has pinned a commit and checked it compiles in MuJoCo WASM. Clone it and drop the folder on the viewport above (MJCF, or URDF with STL/OBJ meshes). Files stay in your tab.
Policies listed for LeKiwi
- source
LeKiwi pick and place (community SmolVLA fine-tune)
LeRobot (SmolVLA) · not replayed in the tab
Train on GPUs
mjlab ships no stock task for LeKiwi. The training page gives you the pinned model and the steps to write a robot config.